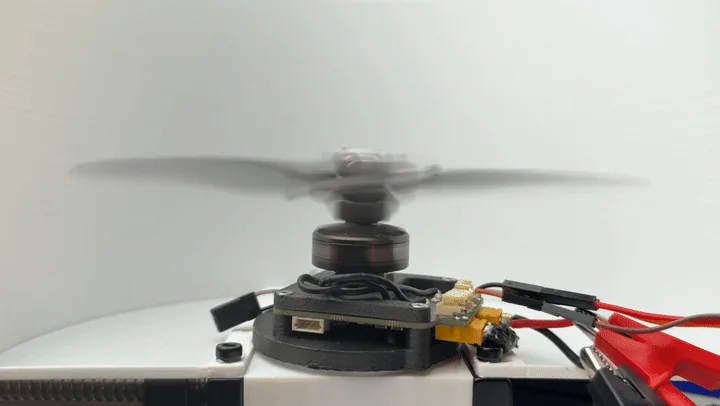
Joshua Bird's drone that flies on one motor and one propeller
Gadget, Hard
A small drone that steers with a single hinged propeller. Speeding the motor up and down at the right point in each turn tilts the blades, so it needs no second motor and no servos. The CAD files and firmware forks are on GitHub.
Each blade sits on a hinge angled at 45 degrees. When the motor speeds up, the blades lag behind the hub, so one pitches up and the other pitches down and the lift on each side changes. Time those speed-ups to the same point in every turn and the drone tilts the way you want, which gives pitch and roll from one motor. Fins on the body resist the spin from motor torque, and quick changes in motor speed handle yaw.
A standard drone ESC lost sync once the speed changes passed about 50 a second, because it estimates rotor position from back-EMF. Bird switched to a moteus r4 controller, which reads position from a magnetic encoder, and got a 6-inch propeller to nearly 20,000 rpm with about 300 speed changes a second. At that speed the propeller turns 20 degrees during a 2 ms command round trip, so he rewrote the moteus firmware to talk straight to the flight controller and work out the commands on board.
Test flights kept crashing from a 160 Hz vibration. His stand-in for a high-speed camera has the motor controller fire a camera flash at a set propeller angle, which freezes the blades in the shot. The photos showed the blades flexing and flapping under load, and stiffer blades fixed it. The newer hub is printed in carbon-fiber PPA on a Bambu Lab H2C.
The magnetometer is unreliable that close to the motor, and the body keeps turning slowly, so the drone corrects its heading every time its infrared sensor sees a beacon in the corner of the room. For now it only flies in a room with that beacon. His next step is a camera that reads the surroundings so it can fly on its own.
The repo has Fusion 360 and STEP files for the body, the prop plate and two propeller versions, and links his ArduPilot fork (GPL-3.0) for the flight controller and his moteus fork (Apache-2.0) for the motor controller. It has no parts list, prices or build steps, and the repo itself has no license file. The 9-minute build video covers the rest.
Ideas to try with it
Our ideas, not the builder's claims.
- Watch the full video before you buy anything, since the repo has no parts list
- Print the hub and prop plate and spin them on a stand first, like the test-stand clip in the README
- Copy the flash trick to photograph any fast-spinning part you're debugging
1 more ideaShow fewer
- Read the diff in the moteus fork to see how the motor controller does the timing on board
- Last commit
- 2026-10-10
- Builder
- jyjblrd
- Repo
- jyjblrd/single-propeller-drone, 563 stars
- Built with
- moteus r4, ArduPilot
Links
What to build next
Builds that share a board, robot or agent with this one.
 ImageGenCam: build a Raspberry Pi camera that remixes every photoAnother AI gadget
 Turn an M5Stack StickS3 into a live-view remote for a RICOH GRAnother AI gadget
 Start with the Cheap Yellow Display: an ESP32 with a built-in touchscreen and a community of projectsAnother AI gadget
 openHASP: build a touchscreen wall panel for Home Assistant from a cheap ESP32 displayAnother AI gadget
 AWTRIX NG: turn a Ulanzi pixel clock into a notification display for your smart home and scriptsAnother AI gadget
 Reflect: a voice-and-light assistant on an M5Stack CoreS3Another AI gadget