Collect robot training data with a handheld UMI gripper
Arm, Hard
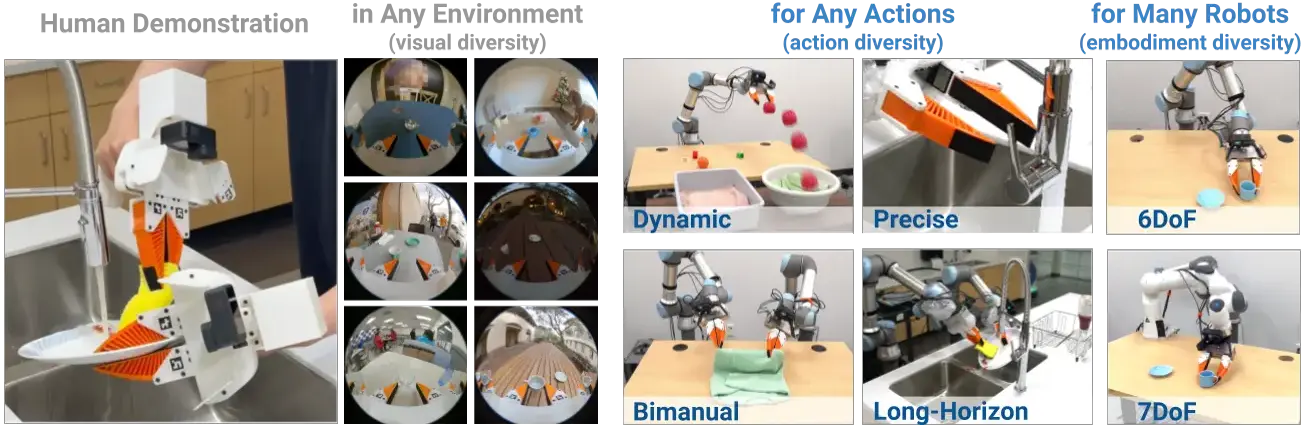
Universal Manipulation Interface (UMI) lets you record manipulation demos by hand with a 3D-printed gripper and a GoPro, then train a Diffusion Policy that runs on real arms.
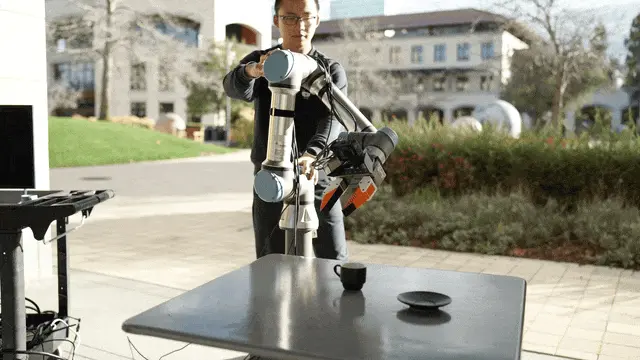
No robot needed to collect data: SLAM on the GoPro video recovers the gripper trajectory. Then deploy on a UR5 or Franka.
Hardware & cost: GoPro, printed gripper, and an arm for deployment; see the hardware guide.
Difficulty: Hard.
Agent install prompt (paste into Claude Code, Cursor or Codex): "Read https://github.com/real-stanford/universal_manipulation_interface, set up its conda env and docker SLAM pipeline, and process the example dataset end to end."
Source: real-stanford/universal_manipulation_interface on GitHub — https://github.com/real-stanford/universal_manipulation_interface (facts checked against the project README, Oct 2026; prices vary by region).
Quick answers
- What do you need to collect robot training data with a handheld UMI gripper?
- GoPro, printed gripper, and an arm for deployment; see the hardware guide.
- How hard is it to collect robot training data with a handheld UMI gripper?
- Hard.
How your agent drives it
Copied from the real-stanford/universal_manipulation_interface README
- Shell
$ python run_slam_pipeline.py example_demo_session
- Shell
$ python train.py --config-name=train_diffusion_unet_timm_umi_workspace task.dataset_path=example_demo_session/dataset.zarr.zip
Any coding agent that can run a shell can run these. Read the README before you run anything on a robot that moves.
Ideas to try with it
Our ideas, not the builder's claims.
- Record cup-arranging demos by hand with a GoPro, no robot needed
- Collect demos in a real kitchen and train a policy back at the lab
- Run the example SLAM pipeline on the sample session
1 more ideaShow fewer
- Swap the training data for your own task and compare results
- Last commit
- 2026-05-26
- Builder
- real-stanford
- Repo
- real-stanford/universal_manipulation_interface, 1,628 stars
- Built with
- UR5, Franka
More like this: Arm manipulation
What to build next
Builds that share a board, robot or agent with this one.
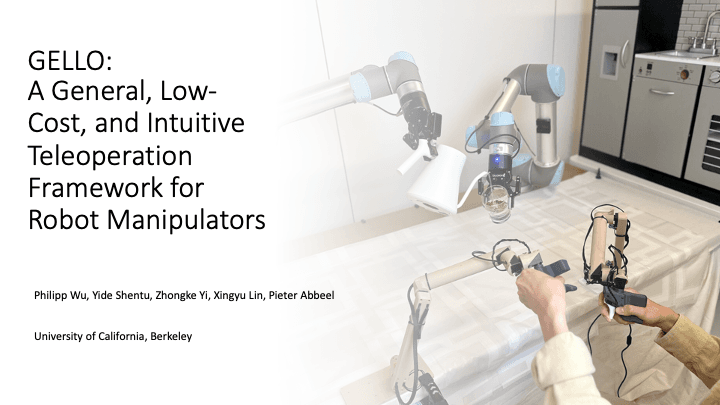 Build a GELLO controller to teleop a robot arm cheaplyAlso built on a Franka or UR5 arm
 Fine-tune Physical Intelligence's π0 model for your robotAnother robot arm
 Train a Diffusion Policy on your own robot demosAlso tagged #diffusion-policy
 Run SmolVLA on an SO-101 so it follows plain-English tasksAnother robot arm
 Teach an SO-101 arm to pick and place with LeRobotAnother robot arm
 Try NVIDIA Isaac GR00T, an open humanoid foundation modelAnother real build