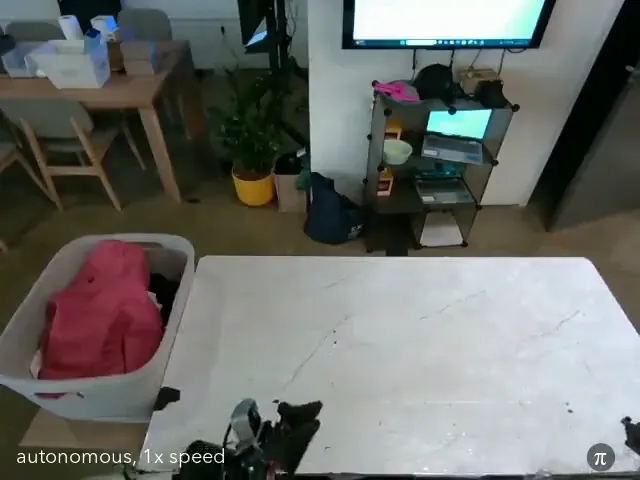
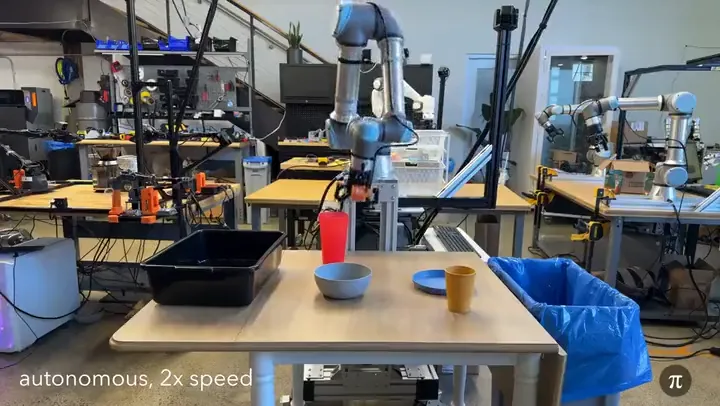
Fine-tune Physical Intelligence's π0 model for your robot
Arm, Hard
openpi is Physical Intelligence's open-source release of π0, π0-FAST and π0.5 vision-language-action models, with checkpoints and fine-tuning code.
Fine-tune a base checkpoint on your own LeRobot-format dataset, then serve the policy to your robot. On X this month a team taught a π model to aim a nerf gun from just 116 demos.
Hardware & cost: A large GPU for fine-tuning (see README memory requirements); any arm with a LeRobot dataset.
Difficulty: Hard.
Agent install prompt (paste into Claude Code, Cursor or Codex): "Clone https://github.com/Physical-Intelligence/openpi, install with uv per the README, and run its LIBERO or ALOHA example inference, then outline fine-tuning on my LeRobot dataset."
Source: Physical-Intelligence/openpi on GitHub — https://github.com/Physical-Intelligence/openpi (facts checked against the project README, Oct 2026; prices vary by region).
Quick answers
- What do you need to fine-tune Physical Intelligence's π0 model for your robot?
- A large GPU for fine-tuning (see README memory requirements); any arm with a LeRobot dataset.
- How hard is it to fine-tune Physical Intelligence's π0 model for your robot?
- Hard.
How your agent drives it
Copied from the Physical-Intelligence/openpi README
- Shell
$ GIT_LFS_SKIP_SMUDGE=1 uv sync
- Shell
$ XLA_PYTHON_CLIENT_MEM_FRACTION=0.9 uv run scripts/train.py pi05_libero --exp-name=my_experiment --overwrite
- Shell
$ uv run scripts/serve_policy.py policy:checkpoint --policy.config=pi05_libero --policy.dir=checkpoints/pi05_libero/my_experiment/20000
Any coding agent that can run a shell can run these. Read the README before you run anything on a robot that moves.
Ideas to try with it
Our ideas, not the builder's claims.
- Fine-tune π0.5 on your own arm demos
- Serve the policy from a GPU box and stream actions to a robot over the network
- Try a released checkpoint on a simulated task first
1 more ideaShow fewer
- Compare π0-FAST and π0.5 on the same task
- Last commit
- 2026-08-24
- Builder
- Physical-Intelligence
- Repo
- Physical-Intelligence/openpi, 14,516 stars
- Built with
- SO-100/SO-101 arm (LeRobot), ALOHA
More like this: SO-101 / LeRobot arms · Arm manipulation
What to build next
Builds that share a board, robot or agent with this one.
 Teleoperate two arms at once with ALOHAAlso built on the SO-101 arm
 Run SmolVLA on an SO-101 so it follows plain-English tasksAlso built on the SO-101 arm
 Try NVIDIA Isaac GR00T, an open humanoid foundation modelAlso built on the SO-101 arm
 Teach an SO-101 arm to pick and place with LeRobotAlso built on the SO-101 arm
 Build the $100-class SO-101 open-source robot armAlso built on the SO-101 arm
 Train a Diffusion Policy on your own robot demosAlso built on the SO-101 arm