Build a GELLO controller to teleop a robot arm cheaply
Arm, Medium
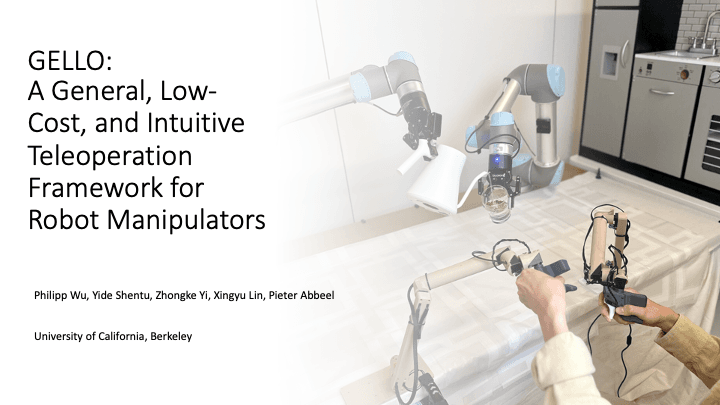
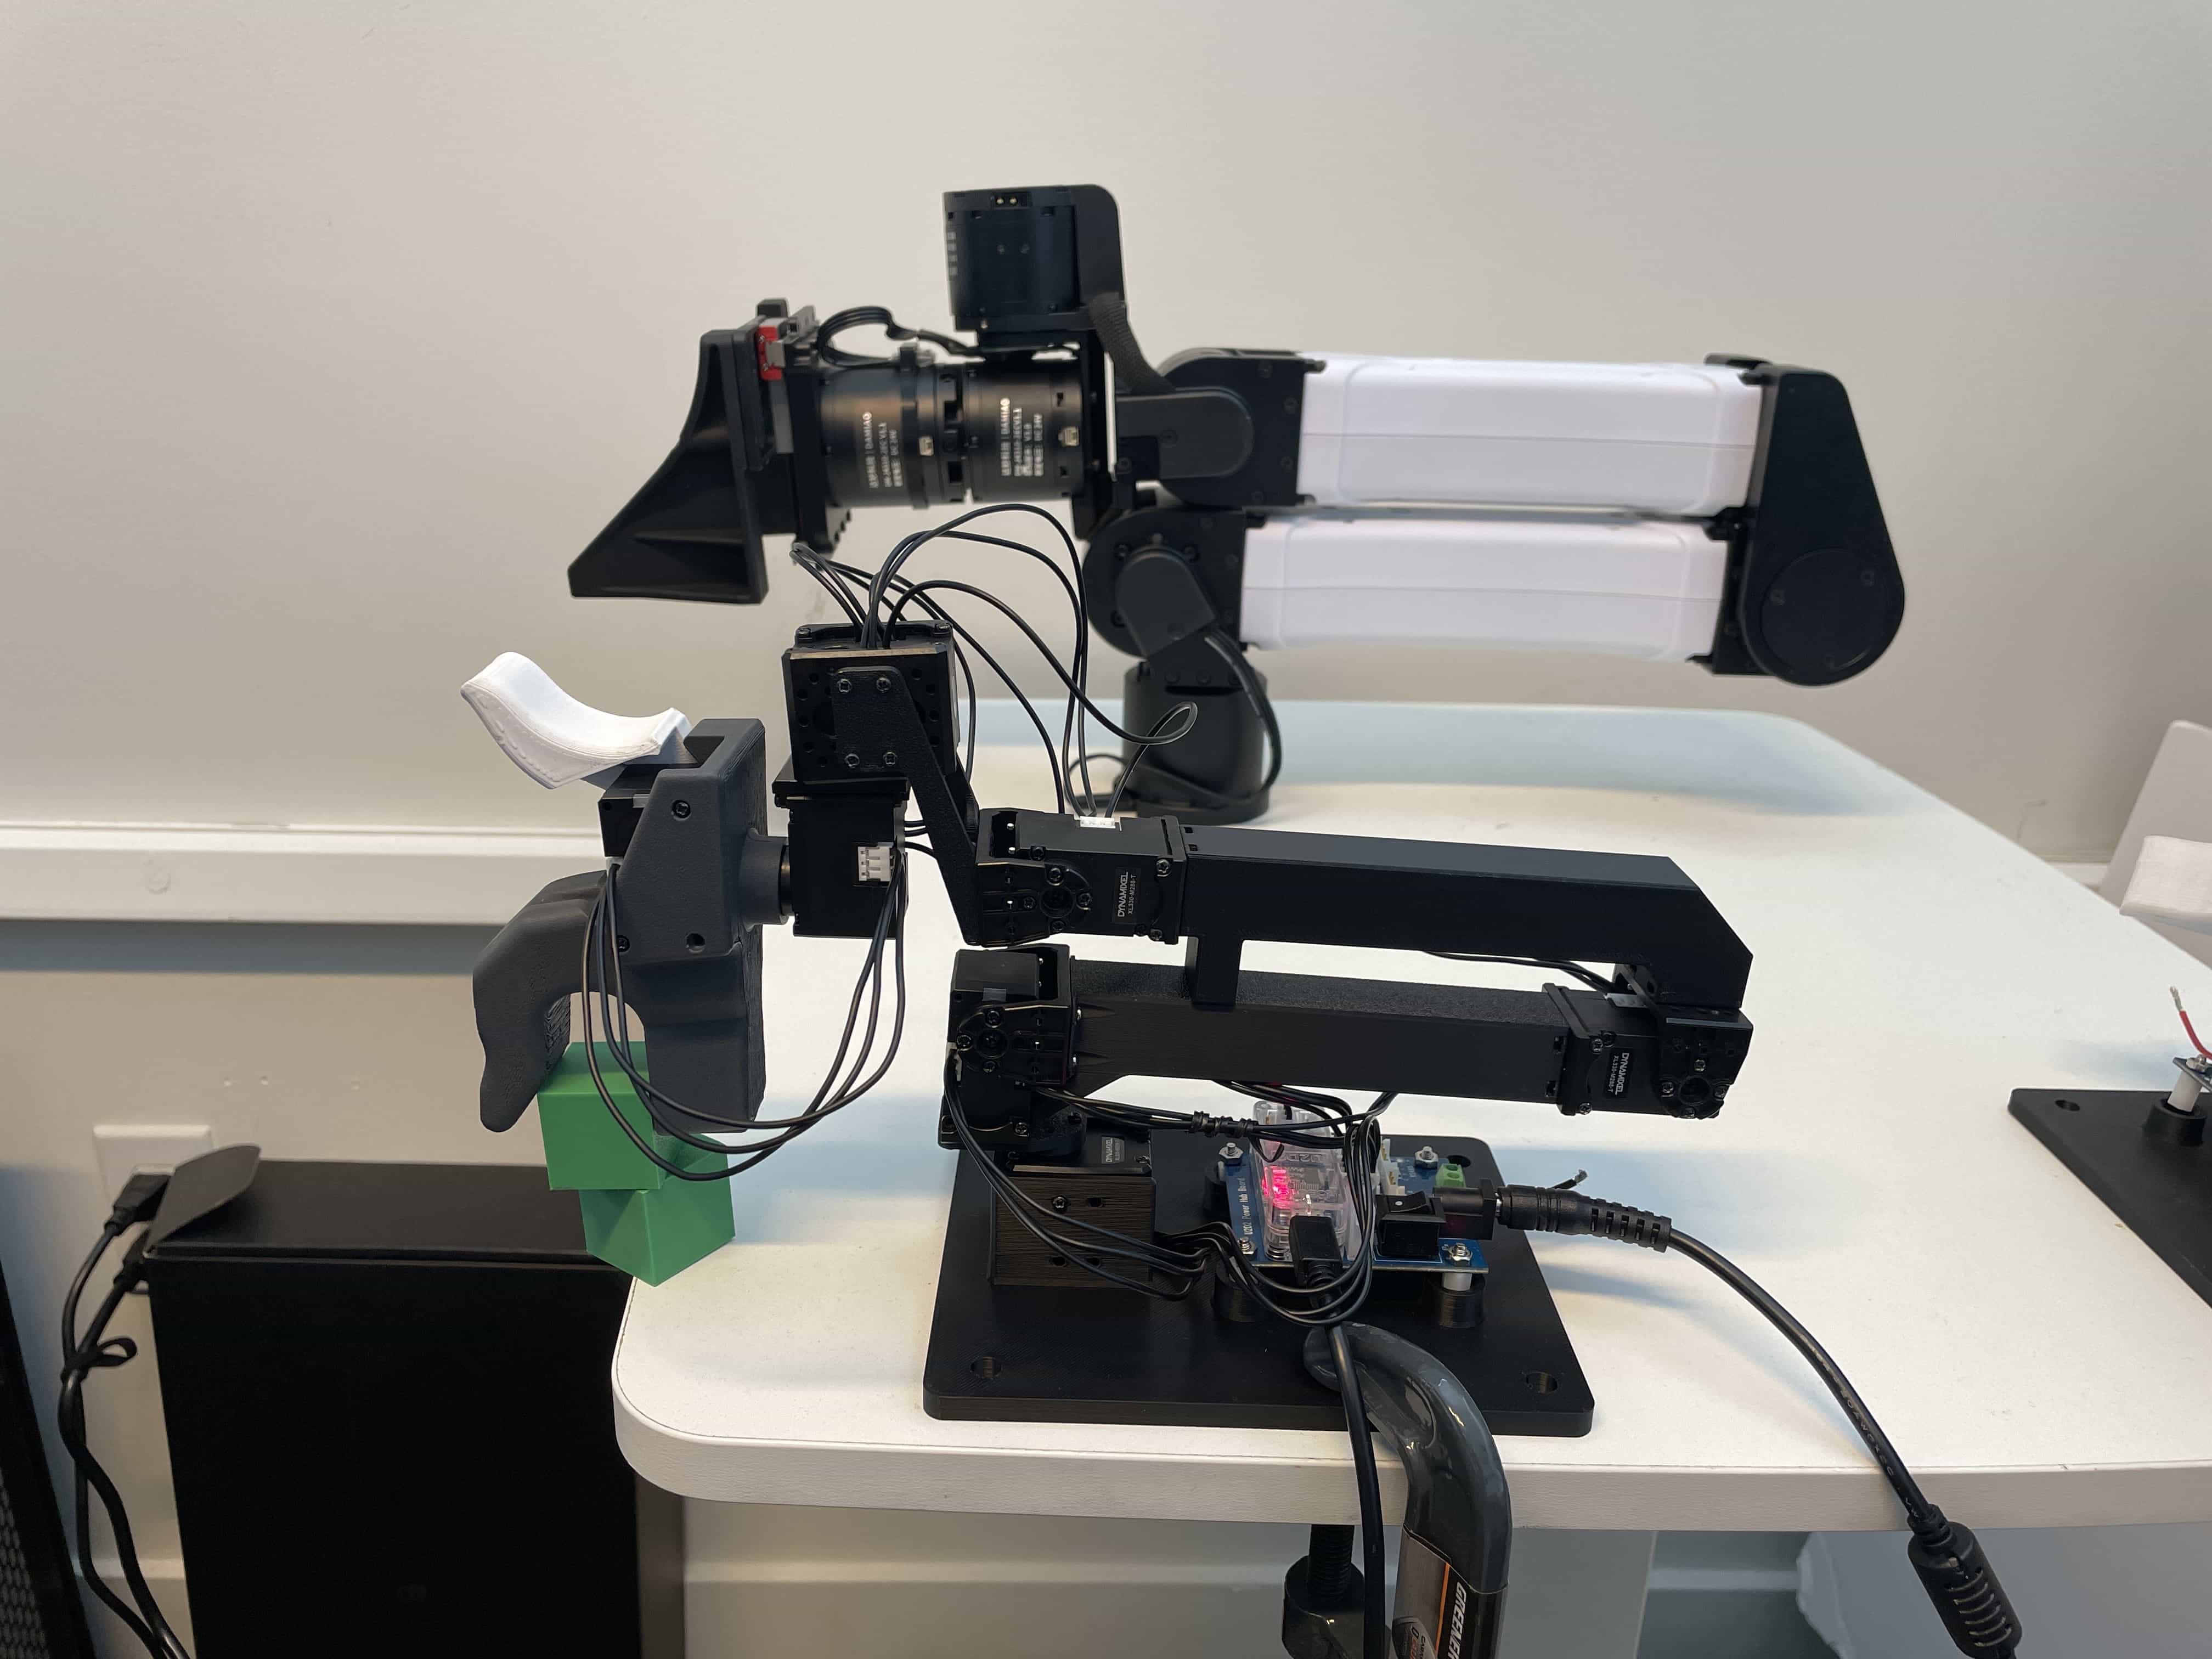
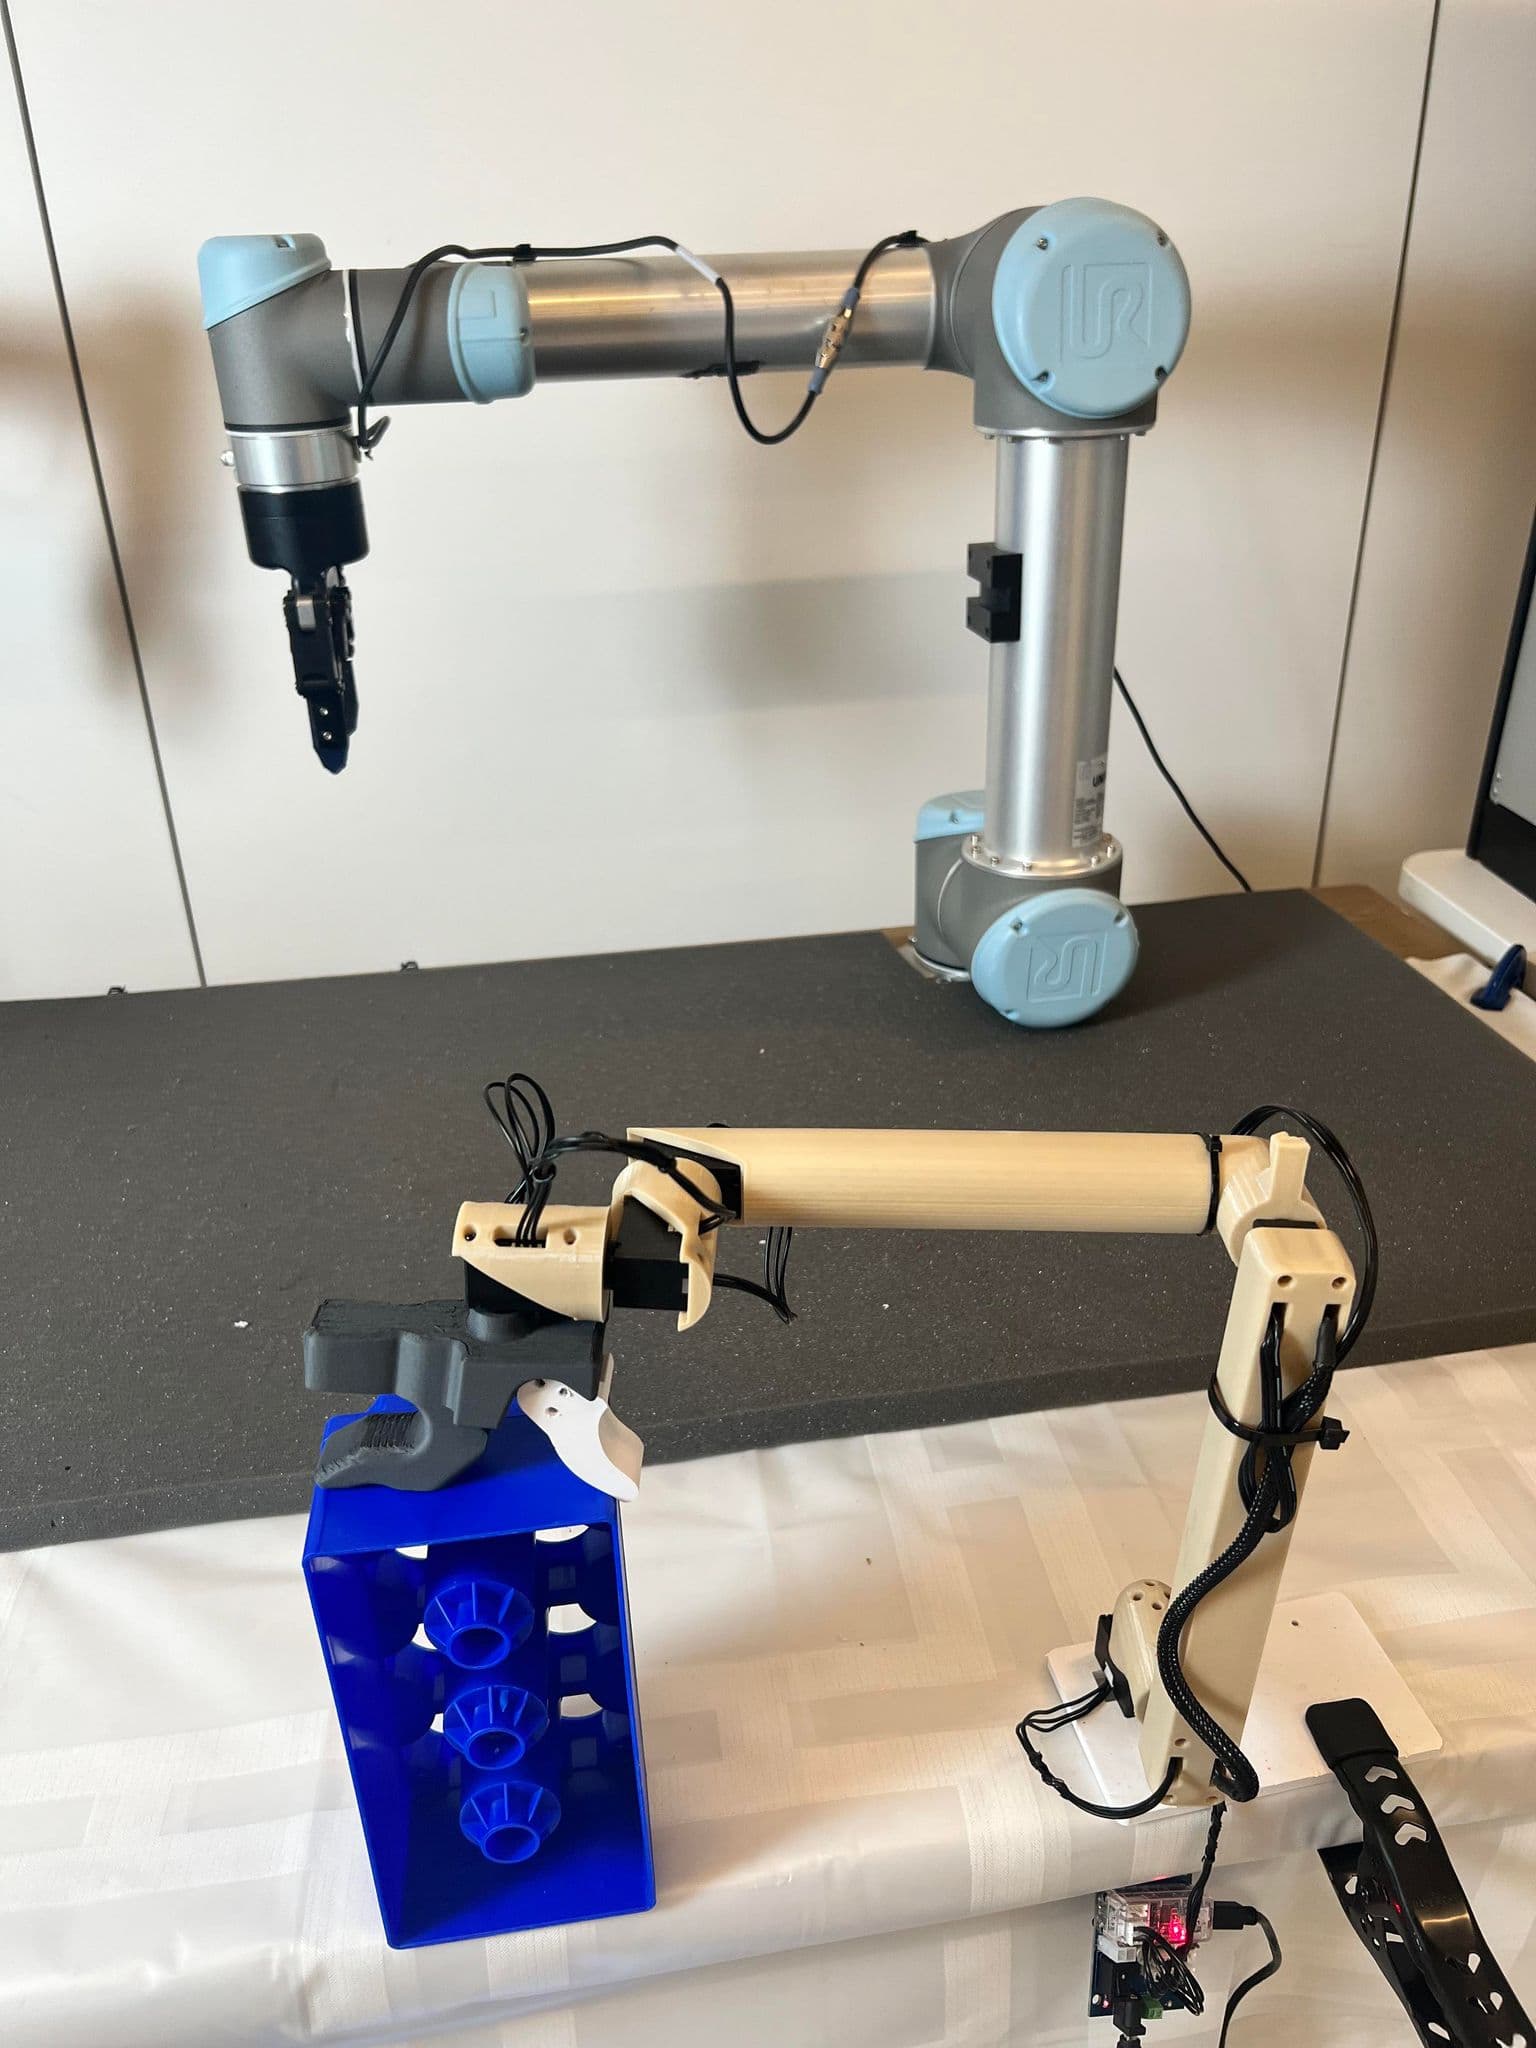
GELLO is a low-cost, intuitive teleop device: a scaled 3D-printed replica of your arm with Dynamixel joints, used to drive Franka, UR or other arms.
Print the GELLO for your arm, read its joints, and stream them to the real robot. The software supports Franka FR3 (ROS 2), Panda, I2RT YAM and more.
Hardware & cost: Dynamixel servos plus printed parts; a few hundred dollars (see the hardware repo).
Difficulty: Medium.
Agent install prompt (paste into Claude Code, Cursor or Codex): "Clone https://github.com/wuphilipp/gello_software, find the GELLO variant for my arm in gello_mechanical, and run the teleop script in simulation first."
Source: wuphilipp/gello_software on GitHub — https://github.com/wuphilipp/gello_software (facts checked against the project README, Oct 2026; prices vary by region).
Quick answers
- What do you need to build a GELLO controller to teleop a robot arm cheaply?
- Dynamixel servos plus printed parts; a few hundred dollars (see the hardware repo).
- How hard is it to build a GELLO controller to teleop a robot arm cheaply?
- Medium.
How your agent drives it
Copied from the wuphilipp/gello_software README
- Shell
$ git clone https://github.com/wuphilipp/gello_software.git
- Shell
$ python experiments/launch_nodes.py --robot <sim_ur|sim_panda|sim_xarm>
- Shell
$ python experiments/run_env.py --agent=gello
Any coding agent that can run a shell can run these. Read the README before you run anything on a robot that moves.
Ideas to try with it
Our ideas, not the builder's claims.
- Puppet a simulated UR arm with a 3D-printed GELLO before touching real hardware
- Collect smooth teleop demos for a Franka faster than with a spacemouse
- Build a pair and run a two-arm setup
1 more ideaShow fewer
- Use it to teach a lab class how joint space control feels
- Last commit
- 2026-09-14
- Builder
- wuphilipp
- Repo
- wuphilipp/gello_software, 562 stars
- Built with
- Franka, UR5, I2RT YAM
More like this: Teleop & remote control · Arm manipulation
What to build next
Builds that share a board, robot or agent with this one.
 Collect robot training data with a handheld UMI gripperAlso built on a Franka or UR5 arm
 The original $250 low-cost robot arm with a leader armAnother robot arm
 Build the Koch v1.1 Dynamixel arm for imitation learningAnother robot arm
 Teach an SO-101 arm to pick and place with LeRobotAnother robot arm
 Build the $100-class SO-101 open-source robot armAnother robot arm
 Teleoperate two arms at once with ALOHAAnother robot arm