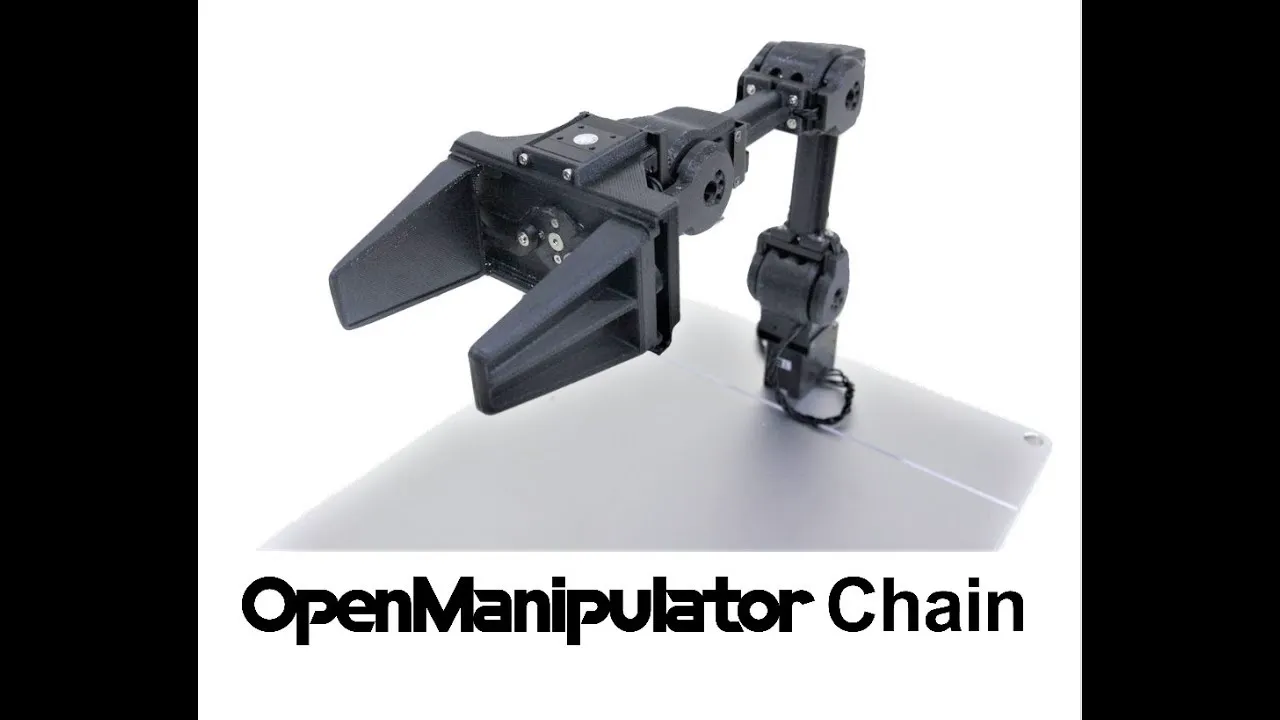
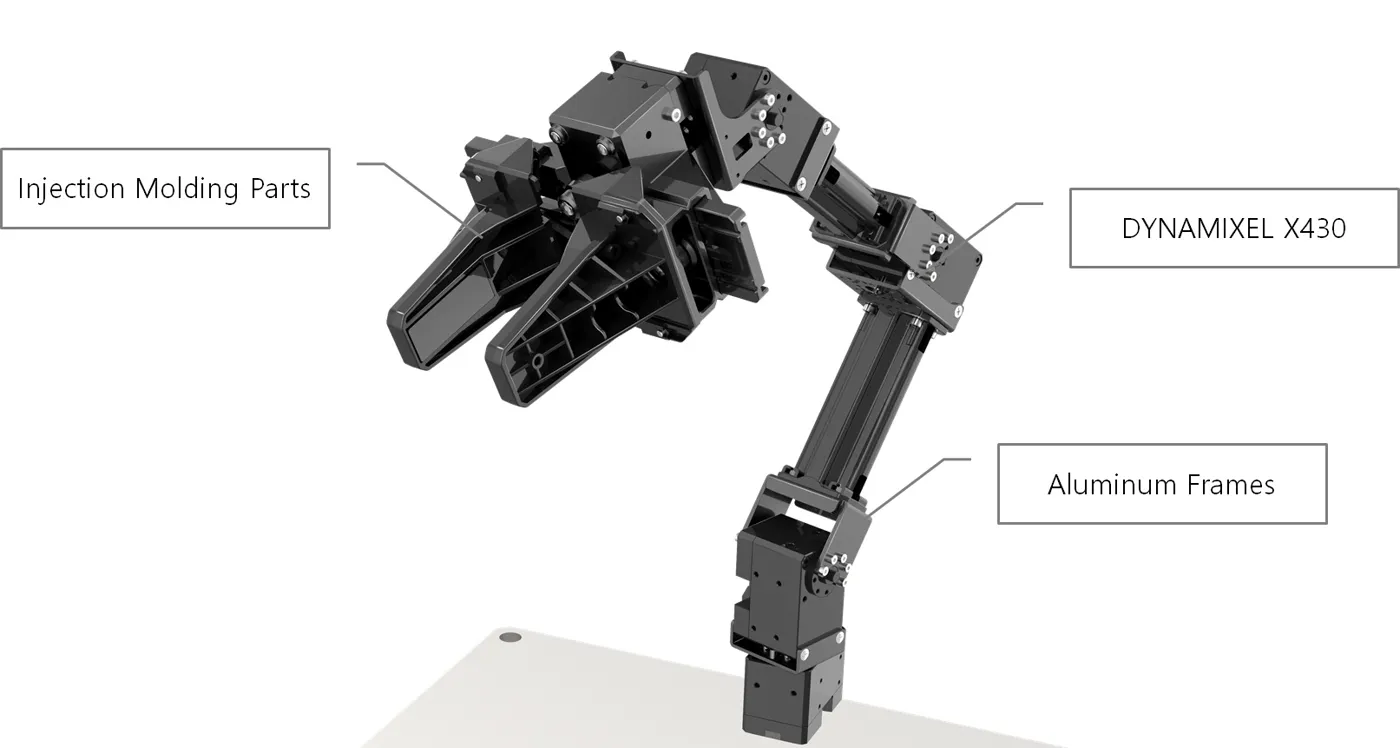
Run ROBOTIS OpenMANIPULATOR with ROS 2 and MoveIt
Arm, Medium
OpenMANIPULATOR from ROBOTIS is an open-source Dynamixel arm with ROS 2 packages for MoveIt planning, teleop and Gazebo, and it mounts on a TurtleBot 3.
Launch the Gazebo model, plan with MoveIt, then control the real arm.
Hardware & cost: OpenMANIPULATOR-X kit (Dynamixel), or sim for free.
Difficulty: Medium.
Agent install prompt (paste into Claude Code, Cursor or Codex): "Clone https://github.com/ROBOTIS-GIT/open_manipulator into a ROS 2 workspace, build it, and launch the Gazebo + MoveIt demo."
Source: ROBOTIS-GIT/open_manipulator on GitHub — https://github.com/ROBOTIS-GIT/open_manipulator (facts checked against the project README, Oct 2026; prices vary by region).
Quick answers
- What do you need to run ROBOTIS OpenMANIPULATOR with ROS 2 and MoveIt?
- OpenMANIPULATOR-X kit (Dynamixel), or sim for free.
- How hard is it to run ROBOTIS OpenMANIPULATOR with ROS 2 and MoveIt?
- Medium.
Ideas to try with it
Our ideas, not the builder's claims.
- Plan pick and place moves in MoveIt and run them on the real arm
- Mount it on a TurtleBot 3 and fetch small objects
- Practice everything in Gazebo first
1 more ideaShow fewer
- Teleop it from a keyboard for a quick demo
- Last commit
- 2026-10-30
- Builder
- ROBOTIS-GIT
- Repo
- ROBOTIS-GIT/open_manipulator, 679 stars
- Built with
- OpenMANIPULATOR, TurtleBot 3/4
More like this: TurtleBot & ROS 2 wheeled kits · Arm manipulation
What to build next
Builds that share a board, robot or agent with this one.
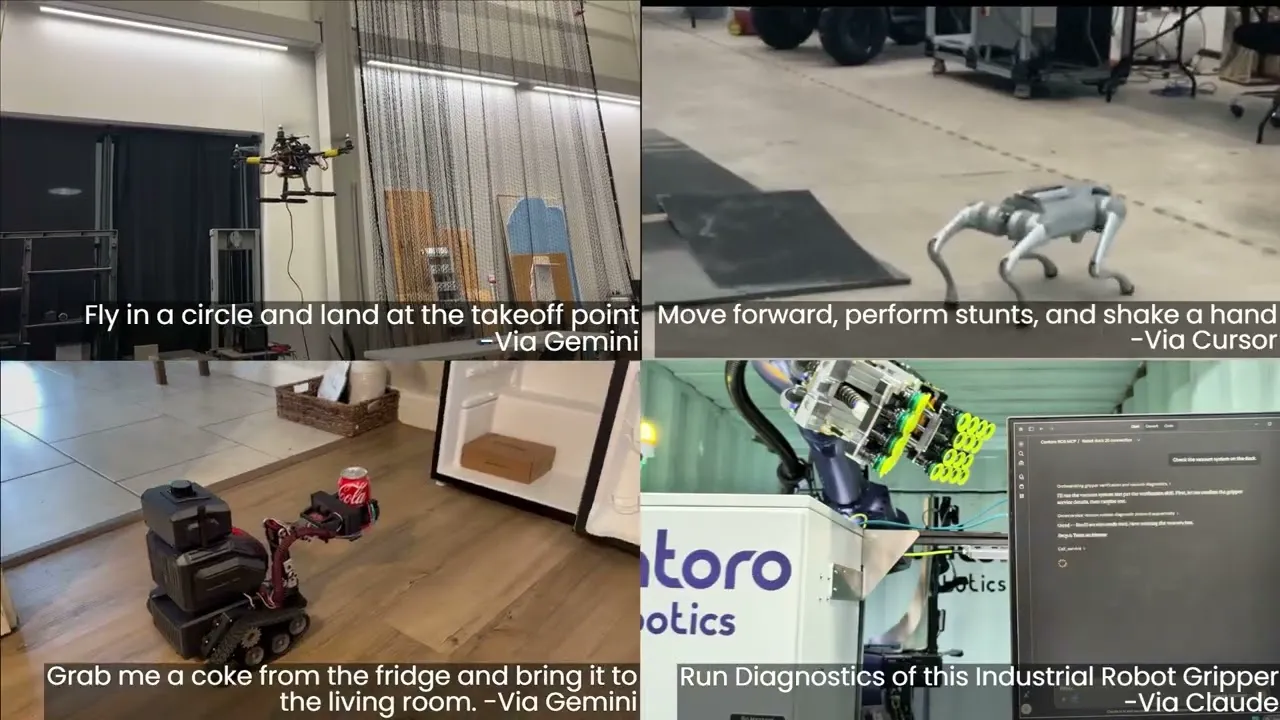 Control any ROS robot from Claude or ChatGPT with ROS MCP ServerAlso built on TurtleBot
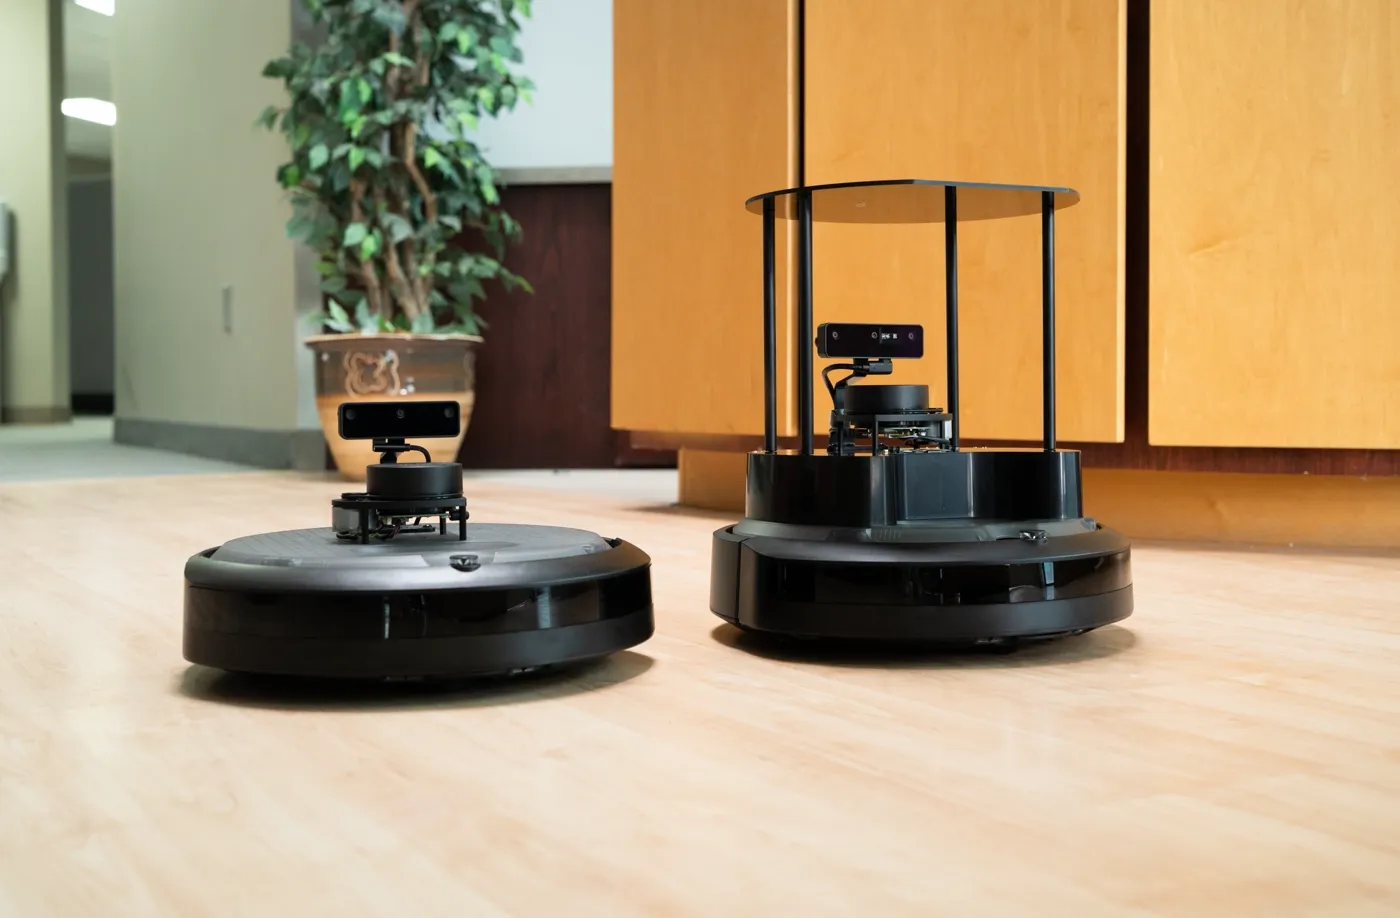 Map your home and navigate with TurtleBot 4Also built on TurtleBot
 Build your own open-source robot vacuum (OOMWOO)Also built on ROS 2
 Ask your robot questions in plain English with NASA JPL's ROSAAlso built on ROS 2
 Run ROS 2 Humble and Nav2 on a Mini PupperAlso built on ROS 2
 Tell Stretch 3 to pick up objects around your homeAlso built on ROS 2