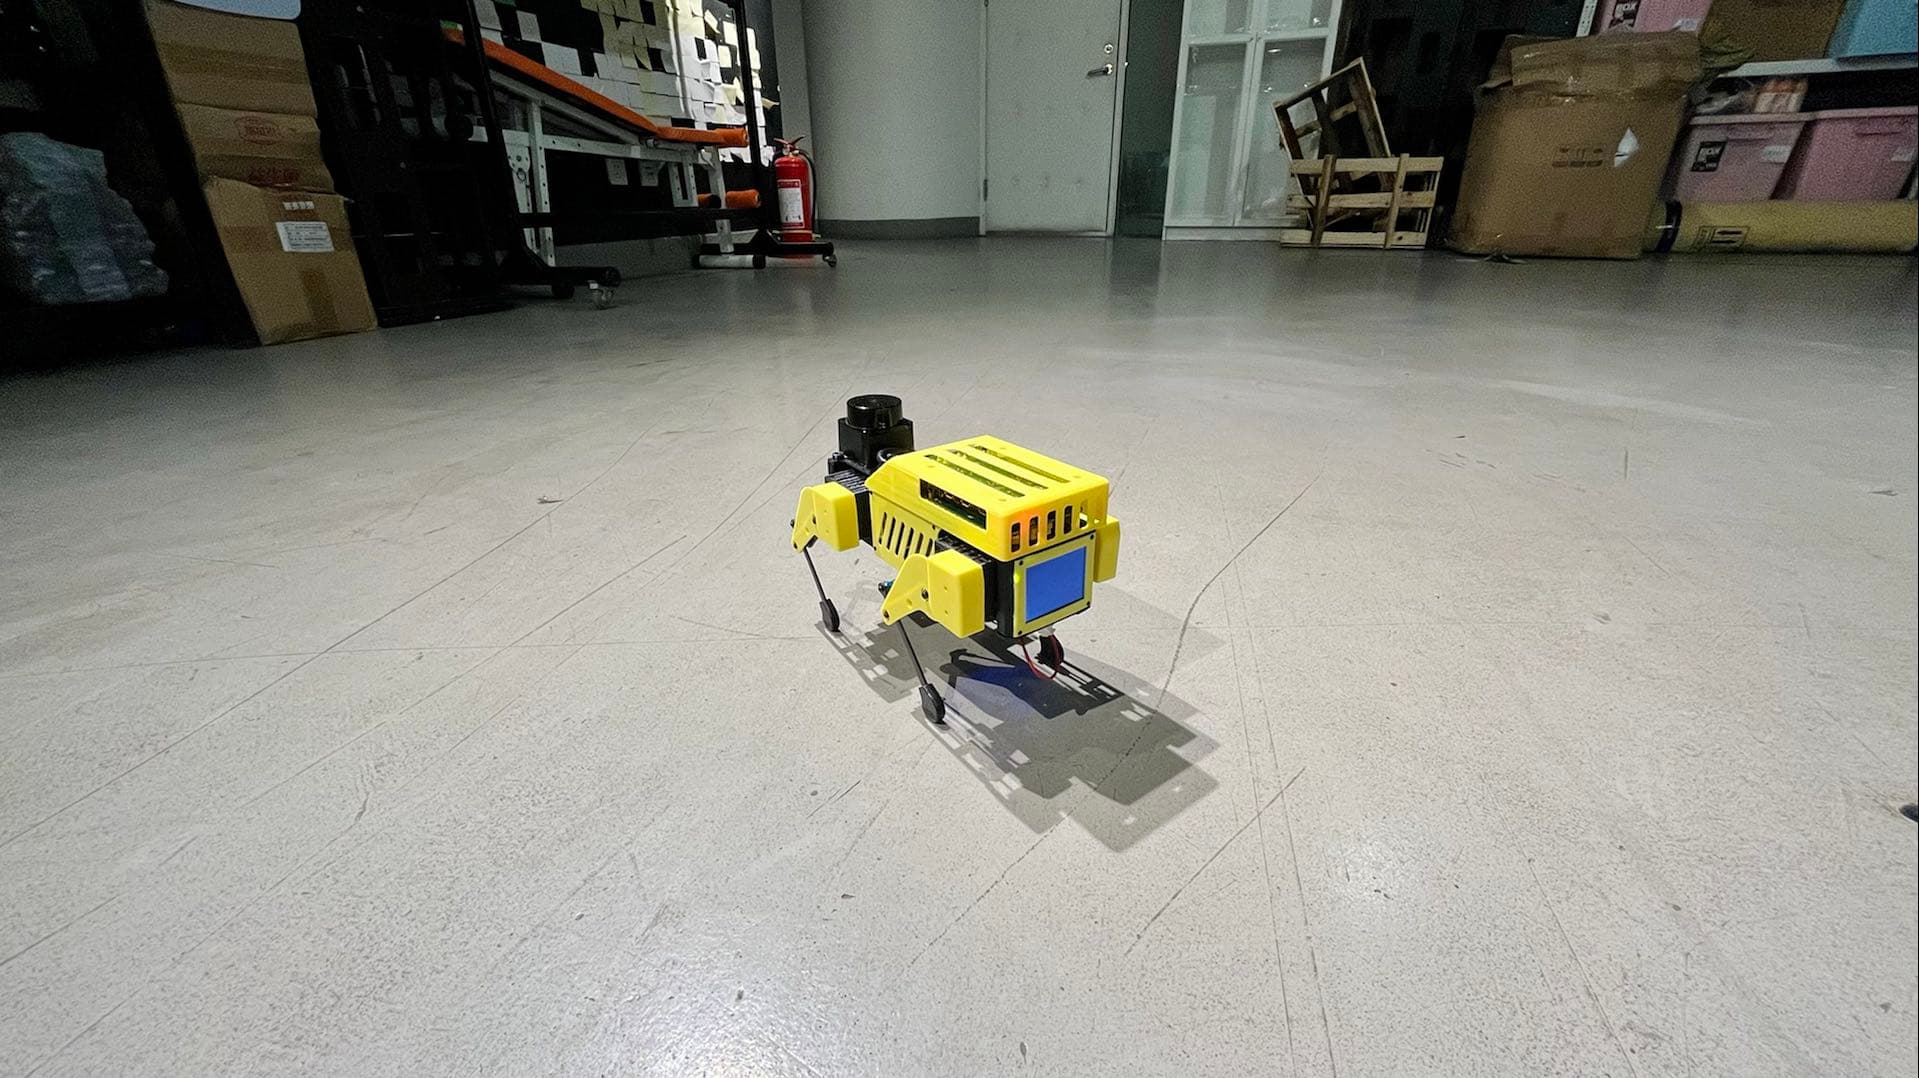


Run ROS 2 Humble and Nav2 on a Mini Pupper
Quad, Medium
Mini Pupper is a small open-source quadruped kit from MangDang; its ROS 2 Humble packages give you teleop, SLAM and navigation.
The mini_pupper_ros repo covers bring-up, Gazebo sim, cartographer mapping and Nav2 on the real dog. A good bridge from wheeled ROS bots to legs.
Hardware & cost: A Mini Pupper 2 kit (see MangDang for pricing) or simulation for free.
Difficulty: Medium.
Agent install prompt (paste into Claude Code, Cursor or Codex): "Set up https://github.com/mangdangroboticsclub/mini_pupper_ros on ROS 2 Humble per the README, launch the Gazebo sim, and teleop it with the keyboard."
Source: mangdangroboticsclub/mini_pupper_ros on GitHub — https://github.com/mangdangroboticsclub/mini_pupper_ros (facts checked against the project README, Oct 2026; prices vary by region).
Quick answers
- What do you need to run ROS 2 Humble and Nav2 on a Mini Pupper?
- A Mini Pupper 2 kit (see MangDang for pricing) or simulation for free.
- How hard is it to run ROS 2 Humble and Nav2 on a Mini Pupper?
- Medium.
How your agent drives it
Copied from the mangdangroboticsclub/mini_pupper_ros README
- Shell
$ ros2 launch mini_pupper_bringup bringup.launch.py
- Shell
$ ros2 run teleop_twist_keyboard teleop_twist_keyboard
Any coding agent that can run a shell can run these. Read the README before you run anything on a robot that moves.
Ideas to try with it
Our ideas, not the builder's claims.
- Drive it around with teleop_twist_keyboard on day one
- Build a SLAM map of your living room and send it to named spots
- Have your agent launch bringup and report when the robot is ready
1 more ideaShow fewer
- Run a nightly patrol and save a photo from each room
- Last commit
- 2026-10-23
- Builder
- mangdangroboticsclub
- Repo
- mangdangroboticsclub/mini_pupper_ros, 195 stars
- Built with
- Mini Pupper
More like this: Nav2 navigation
What to build next
Builds that share a board, robot or agent with this one.
 Map your home and navigate with TurtleBot 4Also built on ROS 2
 Build your own open-source robot vacuum (OOMWOO)Also built on ROS 2
 Ask your robot questions in plain English with NASA JPL's ROSAAlso built on ROS 2
 Control any ROS robot from Claude or ChatGPT with ROS MCP ServerAlso built on ROS 2
 Run ROBOTIS OpenMANIPULATOR with ROS 2 and MoveItAlso built on ROS 2
 Tell Stretch 3 to pick up objects around your homeAlso built on ROS 2