Control any ROS robot from Claude or ChatGPT with ROS MCP Server
Wheeled, Easy
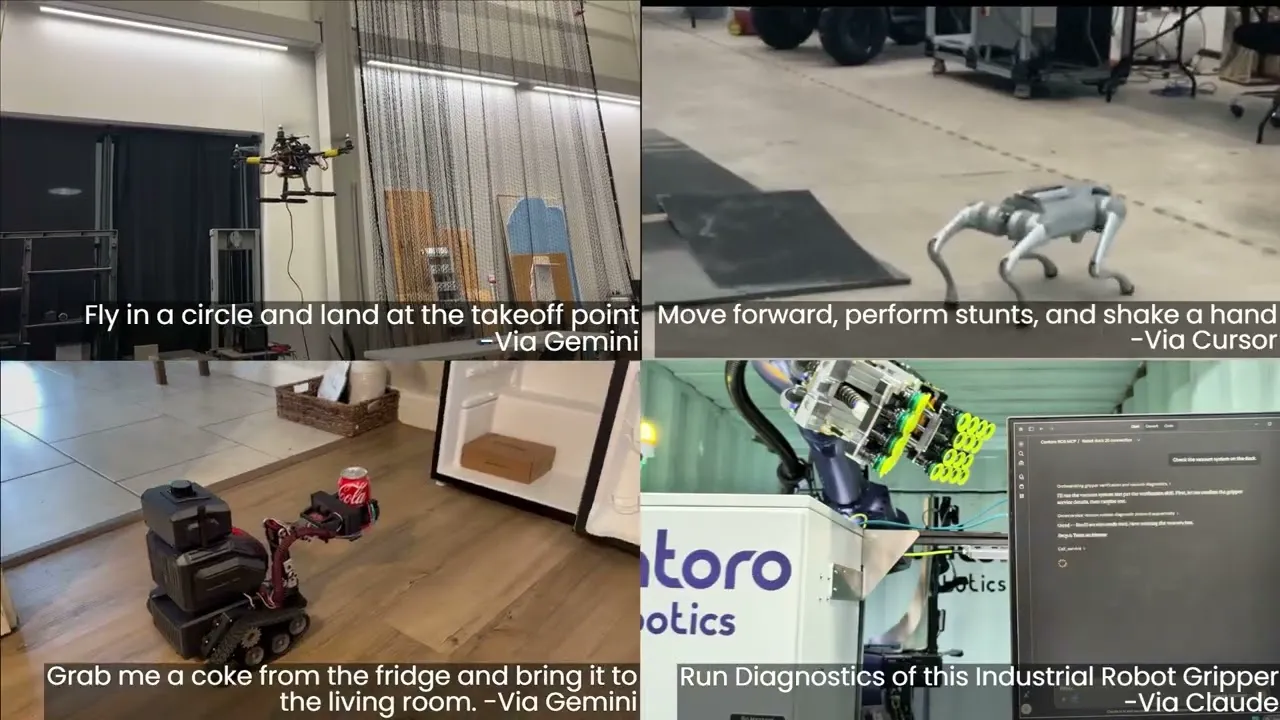
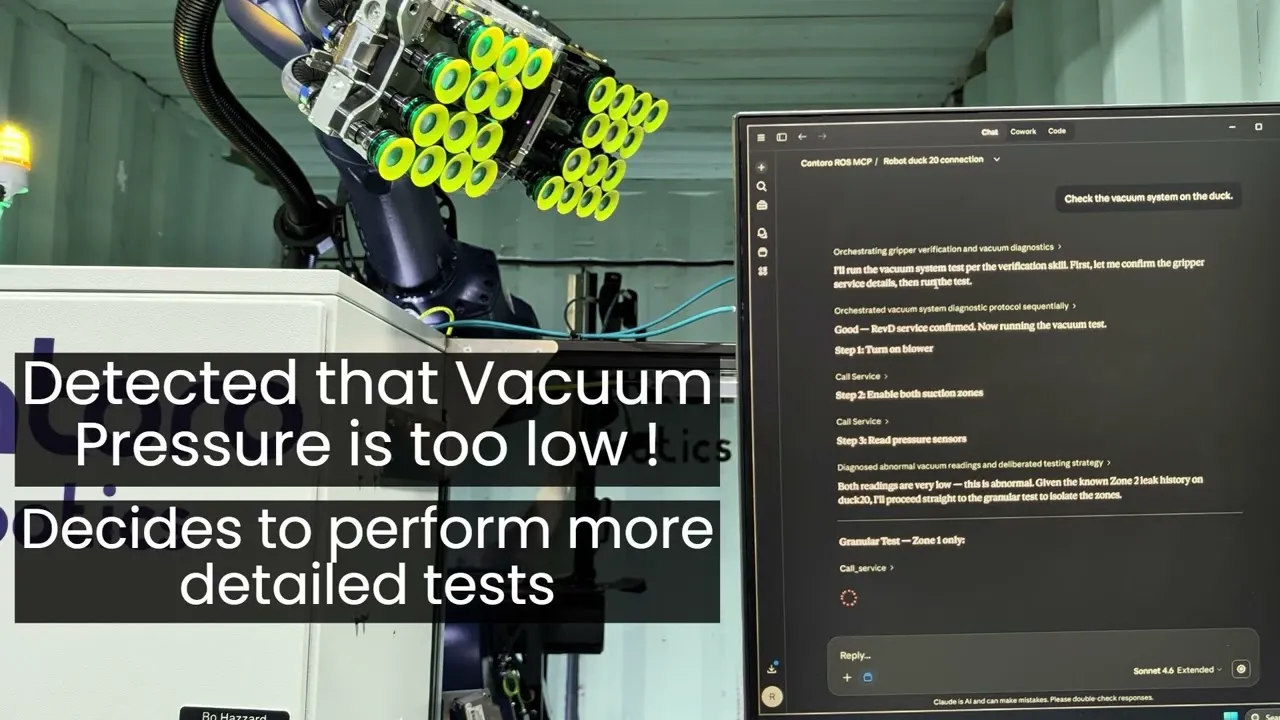
ROS-MCP-Server lets an LLM read topics, call services and send commands to an existing ROS 1 or ROS 2 robot through rosbridge, with no changes to robot code.
Add the rosbridge node to your robot, point an MCP client (Claude Code, Codex CLI, Gemini CLI, Claude Desktop, Cursor) at the server, and ask in plain English: 'what topics exist?', 'drive forward 0.5 m', 'what does the lidar see?'. It discovers message types itself.
Hardware & cost: Any ROS robot or a TurtleBot/Gazebo sim. $0 software.
Difficulty: Easy.
Agent install prompt (paste into Claude Code, Cursor or Codex): "Install https://github.com/robotmcp/ros-mcp-server as an MCP server for this client following the README, make sure rosbridge_server is running on my robot, then list the available topics and read one sensor message."
Source: robotmcp/ros-mcp-server on GitHub — https://github.com/robotmcp/ros-mcp-server (facts checked against the project README, Oct 2026; prices vary by region).
Quick answers
- What do you need to control any ROS robot from Claude or ChatGPT with ROS MCP Server?
- Any ROS robot or a TurtleBot/Gazebo sim. $0 software.
- How hard is it to control any ROS robot from Claude or ChatGPT with ROS MCP Server?
- Easy.
Ideas to try with it
Our ideas, not the builder's claims.
- Ask your agent which topics have publishers and no subscribers
- Tell a TurtleBot to drive to the kitchen in plain English
- Have the agent read battery state and dock the robot when it runs low
1 more ideaShow fewer
- Debug a misbehaving sensor by letting the agent echo its topic
- Last commit
- 2026-11-02
- Builder
- robotmcp
- Repo
- robotmcp/ros-mcp-server, 1,512 stars
- Built with
- TurtleBot 3/4, Any ROS 2 robot
Guides: Give your AI agent a robot body · Robots you can build with AI
What to build next
Builds that share a board, robot or agent with this one.
 Map your home and navigate with TurtleBot 4Also built on TurtleBot
 Run ROBOTIS OpenMANIPULATOR with ROS 2 and MoveItAlso built on TurtleBot
 Ask your robot questions in plain English with NASA JPL's ROSAAlso built on ROS 2
 Build an ESP32 AI voice robot with XiaoZhi and MCPAlso for MCP
 Give Reachy Mini a real-time voice and personalityAlso for MCP
 Tell Stretch 3 to pick up objects around your homeAlso built on ROS 2