Ask your robot questions in plain English with NASA JPL's ROSA
Sim, Easy
ROSA (ROS Agent) from NASA JPL is a LangChain-based assistant for ROS 1 and ROS 2 that lets you inspect and operate a robot with natural-language queries.
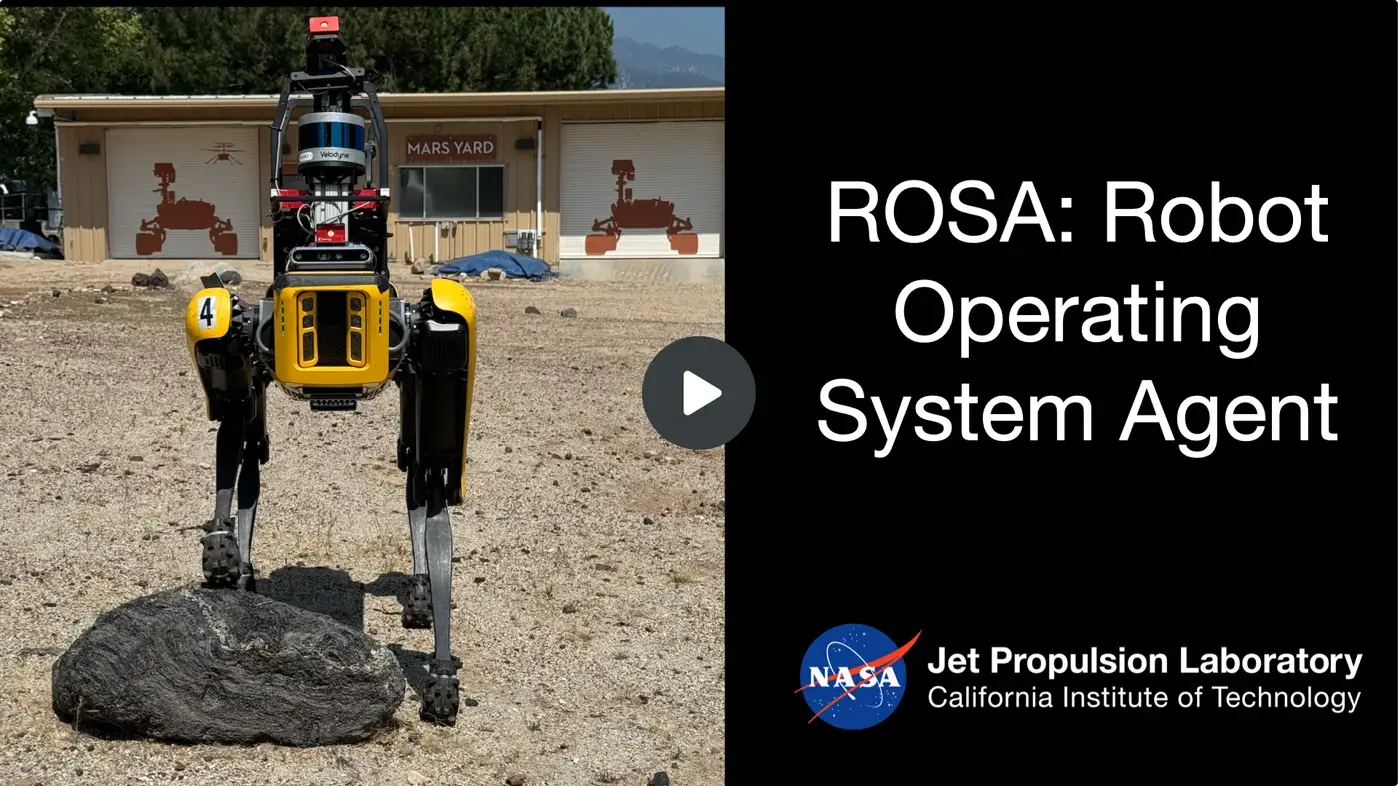
ROSA wraps common ROS tools (list nodes, echo topics, check params, call services) as agent tools, so you can ask 'why is my robot not moving?' and it investigates. JPL demoed it on a Spot robot in its Mars Yard. It ships a TurtleSim demo.
Hardware & cost: A laptop with ROS; $0 software plus LLM API usage.
Difficulty: Easy.
Agent install prompt (paste into Claude Code, Cursor or Codex): "Install ROSA from https://github.com/nasa-jpl/rosa (`pip install jpl-rosa` per the README), run the TurtleSim demo, then adapt it to my ROS 2 robot's topics."
Source: nasa-jpl/rosa on GitHub — https://github.com/nasa-jpl/rosa (facts checked against the project README, Oct 2026; prices vary by region).
Quick answers
- What do you need to ask your robot questions in plain English with NASA JPL's ROSA?
- A laptop with ROS; $0 software plus LLM API usage.
- How hard is it to ask your robot questions in plain English with NASA JPL's ROSA?
- Easy.
How your agent drives it
Copied from the nasa-jpl/rosa README
- Shell
$ pip3 install jpl-rosa
Any coding agent that can run a shell can run these. Read the README before you run anything on a robot that moves.
Ideas to try with it
Our ideas, not the builder's claims.
- Ask 'what nodes are running?' instead of typing ros2 node list
- Have it summarize a log file after a failed run
- Drive TurtleSim with sentences while you learn ROS
1 more ideaShow fewer
- Give it a custom tool that reports your robot's battery
- Source
- nasa-jpl/rosa on GitHub
- Last commit
- 2026-11-03
- Builder
- nasa-jpl
- Repo
- nasa-jpl/rosa, 1,682 stars
- Built with
- Any ROS 2 robot, TurtleSim
Guides: Robots you can build with AI
What to build next
Builds that share a board, robot or agent with this one.
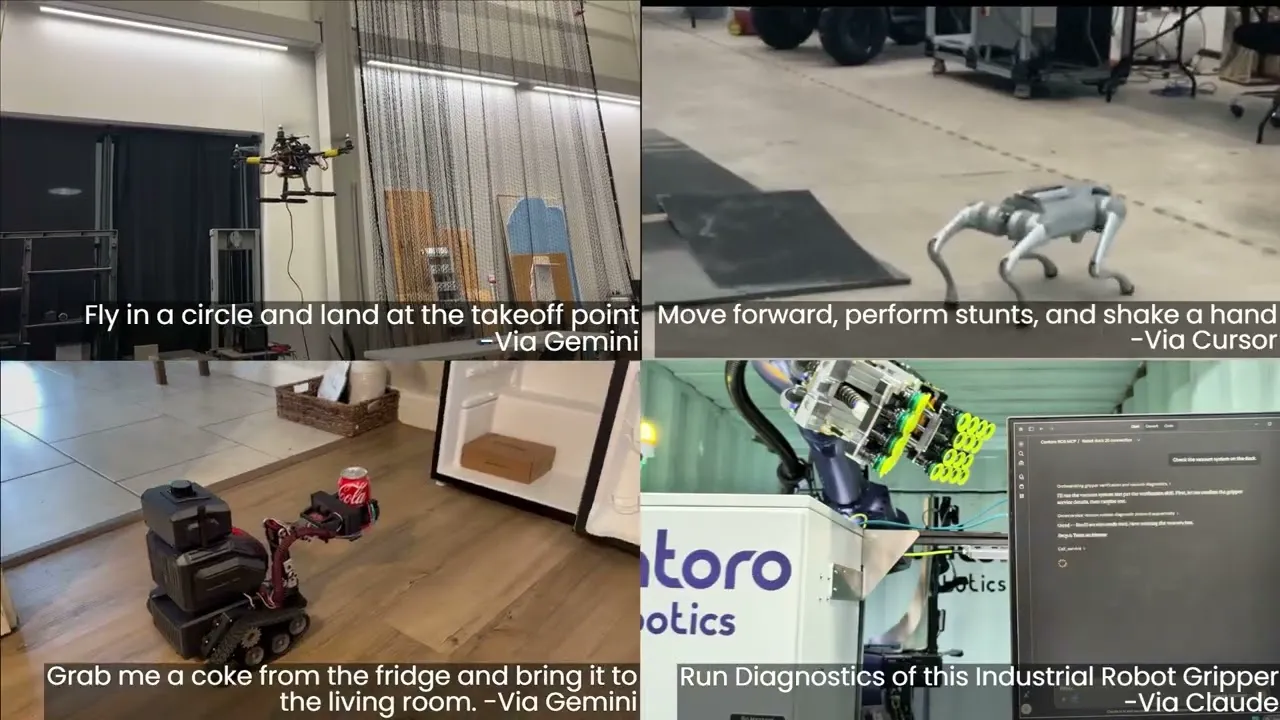 Control any ROS robot from Claude or ChatGPT with ROS MCP ServerAlso built on ROS 2
 Tell Stretch 3 to pick up objects around your homeAlso built on ROS 2
 Build your own open-source robot vacuum (OOMWOO)Also built on ROS 2
 Run ROBOTIS OpenMANIPULATOR with ROS 2 and MoveItAlso built on ROS 2
 Run ROS 2 Humble and Nav2 on a Mini PupperAlso built on ROS 2
 Map your home and navigate with TurtleBot 4Also built on ROS 2