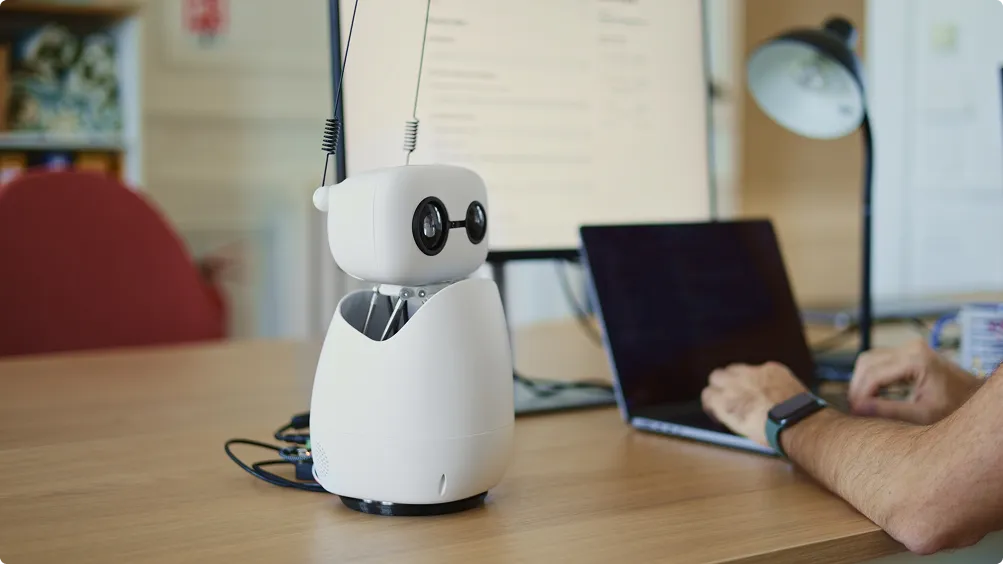
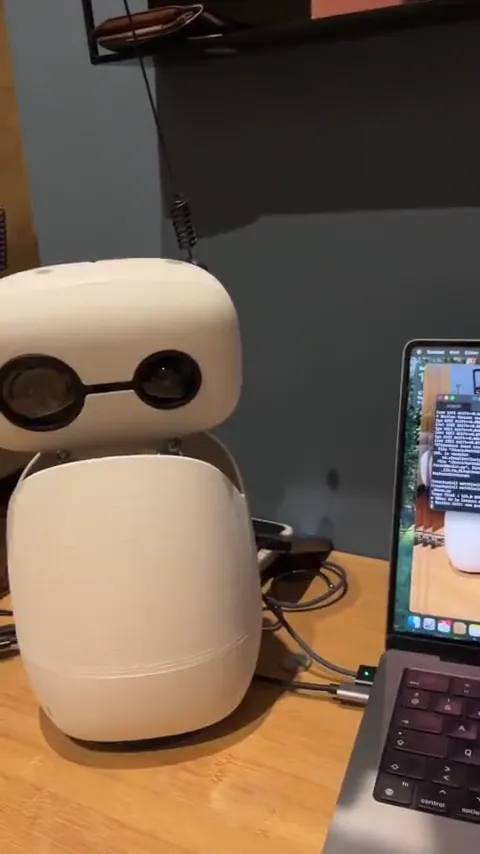
Set up Reachy Mini as a talking desk companion
Humanoid, Easy
Reachy Mini from Pollen Robotics and Hugging Face is an open-source expressive desk robot (moving head, antennas, camera, mics) you program in Python and extend with apps from the Hub.
Reachy Mini comes as a Wireless version, a Lite version that plugs into your computer, or a free simulation. Its Python SDK drives head pose and antennas, and apps install from Hugging Face Spaces. It's one of the most-posted robots on X this month.
Hardware & cost: Reachy Mini Lite is $399 and the Wireless is $499 at hf.co/reachy-mini. If you want it to drive around the room, add Pollen's $149 Hoverboard wheel base. It fits the Wireless only, so a driving Reachy Mini is $648 before shipping (prices checked on pollen-robotics.com/reachy-mini, Oct 30, 2026). You can start in simulation for $0.
Difficulty: Easy.
Agent install prompt (paste into Claude Code, Cursor or Codex): "Clone https://github.com/pollen-robotics/reachy_mini, install the SDK per the README (simulation mode if I don't have the robot), and write a script that makes the head look left, right, then wiggle the antennas."
Source: pollen-robotics/reachy_mini on GitHub — https://github.com/pollen-robotics/reachy_mini (facts checked against the project README, Oct 2026; prices vary by region).
Quick answers
- What do you need to set up Reachy Mini as a talking desk companion?
- Reachy Mini Lite is $399 and the Wireless is $499 at hf.co/reachy-mini. If you want it to drive around the room, add Pollen's $149 Hoverboard wheel base. It fits the Wireless only, so a driving Reachy Mini is $648 before shipping (prices checked on pollen-robotics.com/reachy-mini, Oct 30, 2026). You can start in simulation for $0.
- How hard is it to set up Reachy Mini as a talking desk companion?
- Easy.
How your agent drives it
Copied from the pollen-robotics/reachy_mini README
- Paste into your agent
I'd like to create a Reachy Mini app. Start by reading https://github.com/pollen-robotics/reachy_mini/blob/main/AGENTS.md - Python
from reachy_mini import ReachyMini
from reachy_mini.utils import create_head_pose

with ReachyMini() as mini:
    # Look up and tilt head
    mini.goto_target(
        head=create_head_pose(z=10, roll=15, degrees=True, mm=True),
        duration=1.0
    )
Any coding agent that can run a shell can run these. Read the README before you run anything on a robot that moves.
Ideas to try with it
Our ideas, not the builder's claims.
- Have it look up and wiggle its antennas when a build finishes
- Read your calendar out loud at 8am and nod at each meeting
- Turn toward whoever is speaking on a video call
1 more ideaShow fewer
- Publish a small app to the Hugging Face Hub for other owners
- Last commit
- 2026-11-03
- Builder
- pollen-robotics
- Repo
- pollen-robotics/reachy_mini, 1,634 stars
- Built with
- Reachy Mini
Reachy Mini, 3 builds: Set up Reachy Mini as a talking desk companion · Give Reachy Mini a real-time voice and personality · Make Reachy Mini move with emotion in real time
Parts notes for this device are in the Hermes Workshop catalog.
What to build next
Builds that share a board, robot or agent with this one.
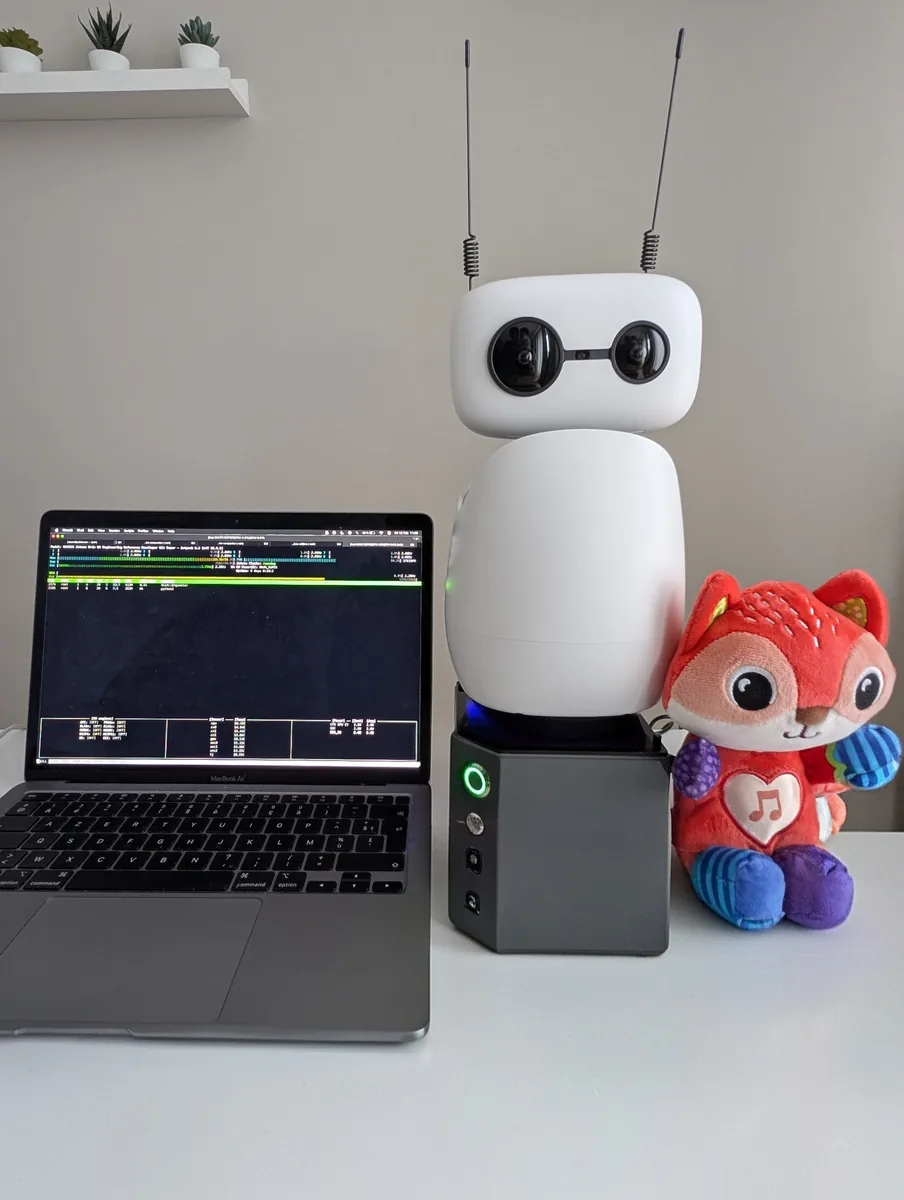 Turn Reachy Mini into a fully local baby companionAlso built on Reachy Mini
 Give Reachy Mini a real-time voice and personalityAlso built on Reachy Mini
 Make Reachy Mini move with emotion in real timeAlso built on Reachy Mini
 Try NVIDIA Isaac GR00T, an open humanoid foundation modelAnother humanoid
 Bring a secondhand Anki Vector back to life with wire-podAlso tagged #desk-robot
 Fine-tune Physical Intelligence's π0 model for your robotAnother real build