MOSS: a 3D-printed rover that picks up litter
Wheeled, Hard, $460
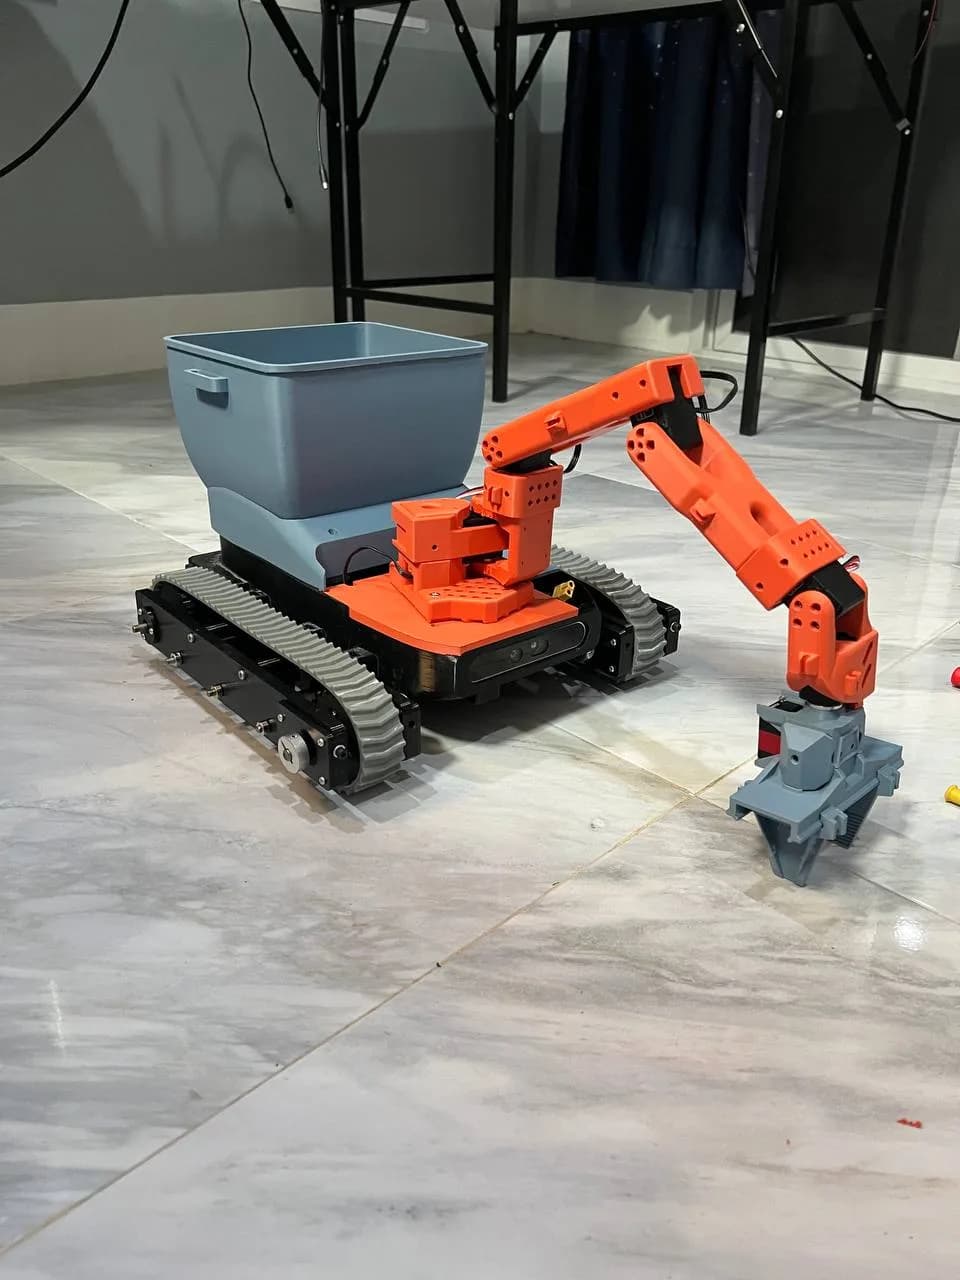
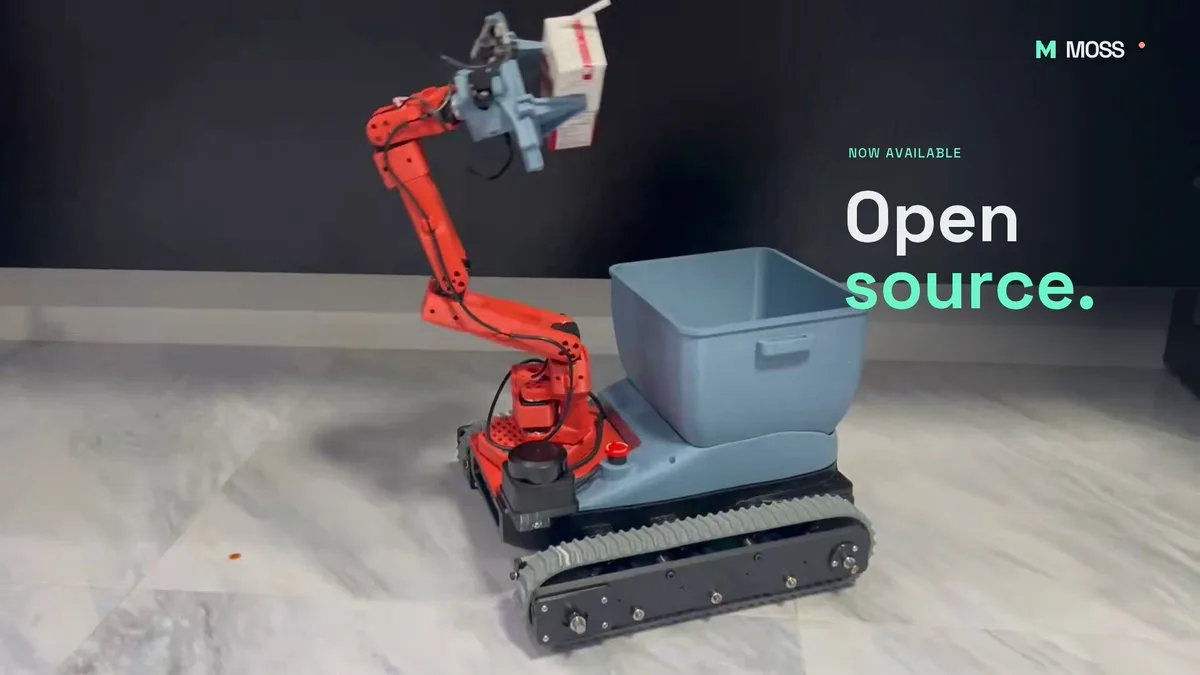
MOSS is an open-source tracked rover with an SO-101-derived arm, a parallel gripper and a bin on top. You print and build it yourself, and the base parts come to about $460 before the computer and navigation camera.
Cost $460: MOSS README: base assembly about $460 in parts; the computer and navigation camera are extra.
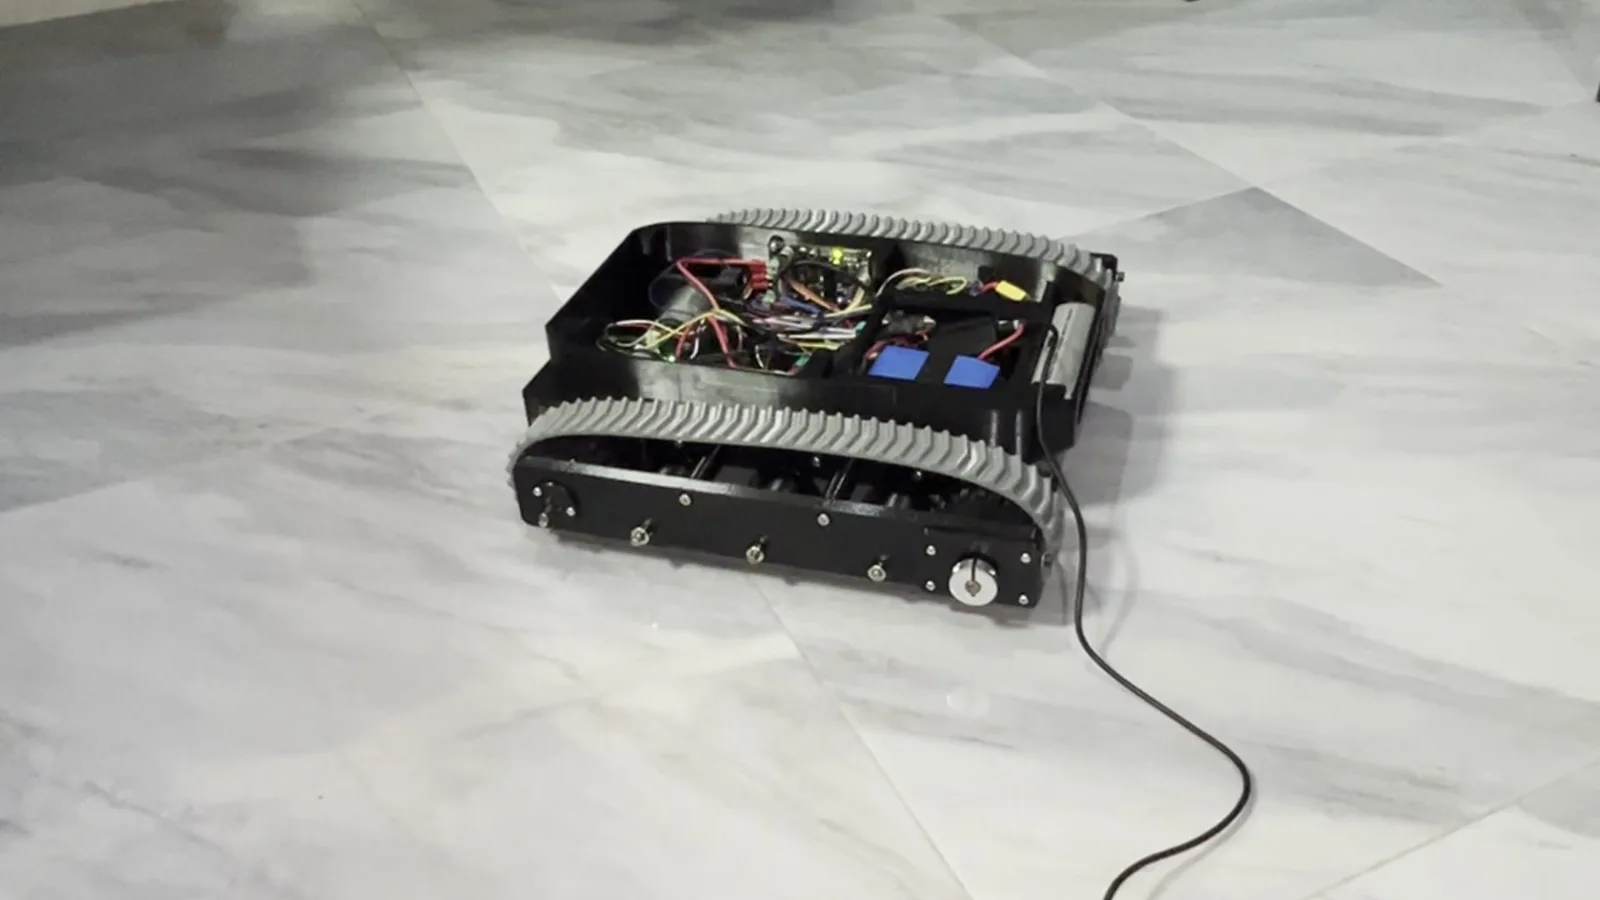
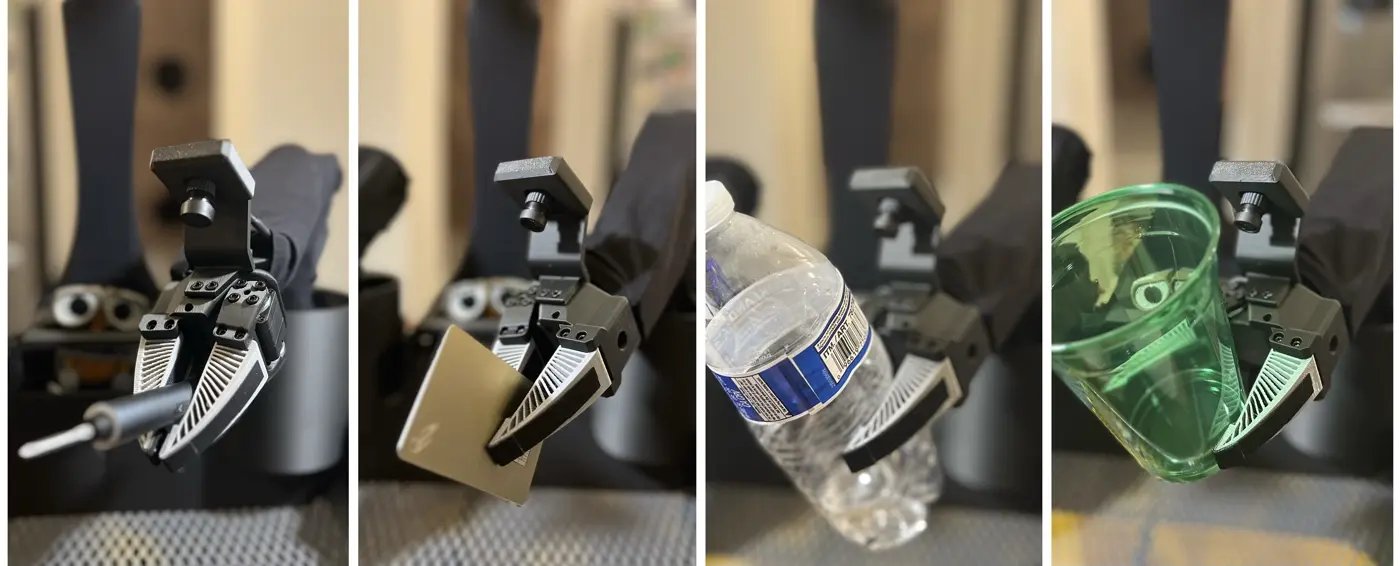
metr0x picks up litter by hand on walks and wanted a robot to do the same. MOSS has a tracked base with two geared DC motors driven by an ESP32-S3, a bin you empty by hand, and an arm derived from the SO-101 with a NormaCore parallel gripper widened to a 90 mm grip. A depth camera sits at the nose, a color camera rides in the hand, and a 2D lidar handles navigation. dimOS runs teleop, recording, navigation and manipulation.
You pick one compute setup on top of the base: Jetson Orin Nano Super with a RealSense D455, Raspberry Pi 5 with a Hailo AI HAT and an Orbbec Gemini 2, or Raspberry Pi 5 with a Mighty camera. The README lists the extra cost of each and the BOM has every part. The V0.6 / R92 CAD, STL files and assembly guide went up on October 16, 2026, and the builder used Codex on the CAD revisions.
The rover drives and does pick-and-drop moves today. The README says autonomous litter picking and a full field test haven't been shown yet. It also warns that the lithium battery has no certified protection, so put the rover on blocks for its first run. Kits are planned through TNKR. Code is Apache-2.0, hardware is CERN-OHL-S-2.0, and docs and media are CC BY 4.0.
Quick answers
- How much does MOSS cost to build?
- About $460, per the MOSS README: base assembly about $460 in parts; the computer and navigation camera are extra.
- How hard is MOSS to build?
- We list it as hard.
Ideas to try with it
Our ideas, not the builder's claims.
- Drive it by teleop in a park first and record the pickups as training data
- Run the MuJoCo model before you print a single part
- Start with the cheapest Pi 5 + Mighty camera setup and upgrade later
1 more ideaShow fewer
- Teach it one object, like cans, before trying mixed litter
- Last commit
- 2026-11-02
- Builder
- @metrox_eth
- Repo
- metrox-eth/moss, 126 stars
- Built with
- ESP32-S3, Jetson Orin Nano, Raspberry Pi 5, SO-100/SO-101 arm (LeRobot)
Links
Guides: Codex and ChatGPT hardware projects people actually built
What to build next
Builds that share a board, robot or agent with this one.
 ImageGenCam: build a Raspberry Pi camera that remixes every photoAlso for Codex
 Put an SO-101 arm on wheels with LeKiwiAlso built on the SO-101 arm
 Cat TV: a Raspberry Pi that projects scenes for a catAlso for Codex
 A farmer's ESP32 greenhouse vent opener, controlled from LINEAlso for Codex
 Make an RC car drive itself with DonkeycarAlso built on Jetson
 Build the $100-class SO-101 open-source robot armAlso built on the SO-101 arm