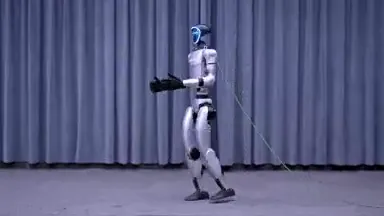
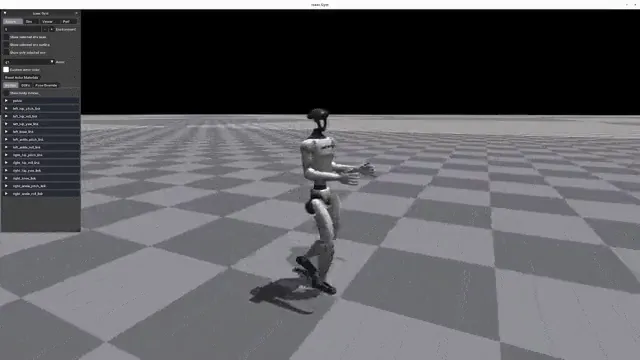
Train a walking policy for Unitree Go2, H1 or G1 in sim
Quad, Hard
Unitree RL GYM trains reinforcement-learning locomotion in Isaac Gym, validates it in MuJoCo, then deploys it to physical Unitree robots.
The official repo supports Go2, H1, H1_2 and G1 with a train, play, sim2sim (MuJoCo), sim2real flow. You can do the whole thing without owning the robot.
Hardware & cost: An NVIDIA GPU for Isaac Gym. A Unitree robot only if you deploy (Go2 starts in the low thousands of dollars).
Difficulty: Hard.
Agent install prompt (paste into Claude Code, Cursor or Codex): "Set up https://github.com/unitreerobotics/unitree_rl_gym following the README (Isaac Gym + rsl_rl), train the Go2 task for a short run, then play it back in MuJoCo sim2sim."
Source: unitreerobotics/unitree_rl_gym on GitHub — https://github.com/unitreerobotics/unitree_rl_gym (facts checked against the project README, Oct 2026; prices vary by region).
Quick answers
- What do you need to train a walking policy for Unitree Go2, H1 or G1 in sim?
- An NVIDIA GPU for Isaac Gym. A Unitree robot only if you deploy (Go2 starts in the low thousands of dollars).
- How hard is it to train a walking policy for Unitree Go2, H1 or G1 in sim?
- Hard.
How your agent drives it
Copied from the unitreerobotics/unitree_rl_gym README
- Shell
$ python legged_gym/scripts/train.py --task=xxx
- Shell
$ python legged_gym/scripts/play.py --task=xxx
- Shell
$ python deploy/deploy_mujoco/deploy_mujoco.py g1.yaml
Any coding agent that can run a shell can run these. Read the README before you run anything on a robot that moves.
Ideas to try with it
Our ideas, not the builder's claims.
- Train a walking policy in Isaac Gym and check it in MuJoCo before touching hardware
- Teach a Go2 a slower, quieter gait for indoor use
- Compare two reward settings and keep the one that falls less
1 more ideaShow fewer
- Have your agent run a training sweep overnight and report the best checkpoint
- Last commit
- 2025-07-25
- Builder
- unitreerobotics
- Repo
- unitreerobotics/unitree_rl_gym, 3,654 stars
- Built with
- Unitree Go2, Unitree G1, Unitree H1
Unitree, 2 builds: Train a walking policy for Unitree Go2, H1 or G1 in sim · Write your own controller for a Unitree robot with SDK2
Parts notes for this device are in the Hermes Workshop catalog.
What to build next
Builds that share a board, robot or agent with this one.
 Write your own controller for a Unitree robot with SDK2Also built on Unitree
 Try NVIDIA Isaac GR00T, an open humanoid foundation modelAlso built on Unitree
 Build ToddlerBot, a low-cost open humanoid for learningAlso tagged #mujoco
 Program a robot cat or dog with Petoi OpenCatAnother robot dog
 Build a 3D-printed Spot Micro with ROS and SLAMAnother robot dog
 Build Stanford Pupper v3, a ~$1,000 RL-walking quadrupedAnother robot dog