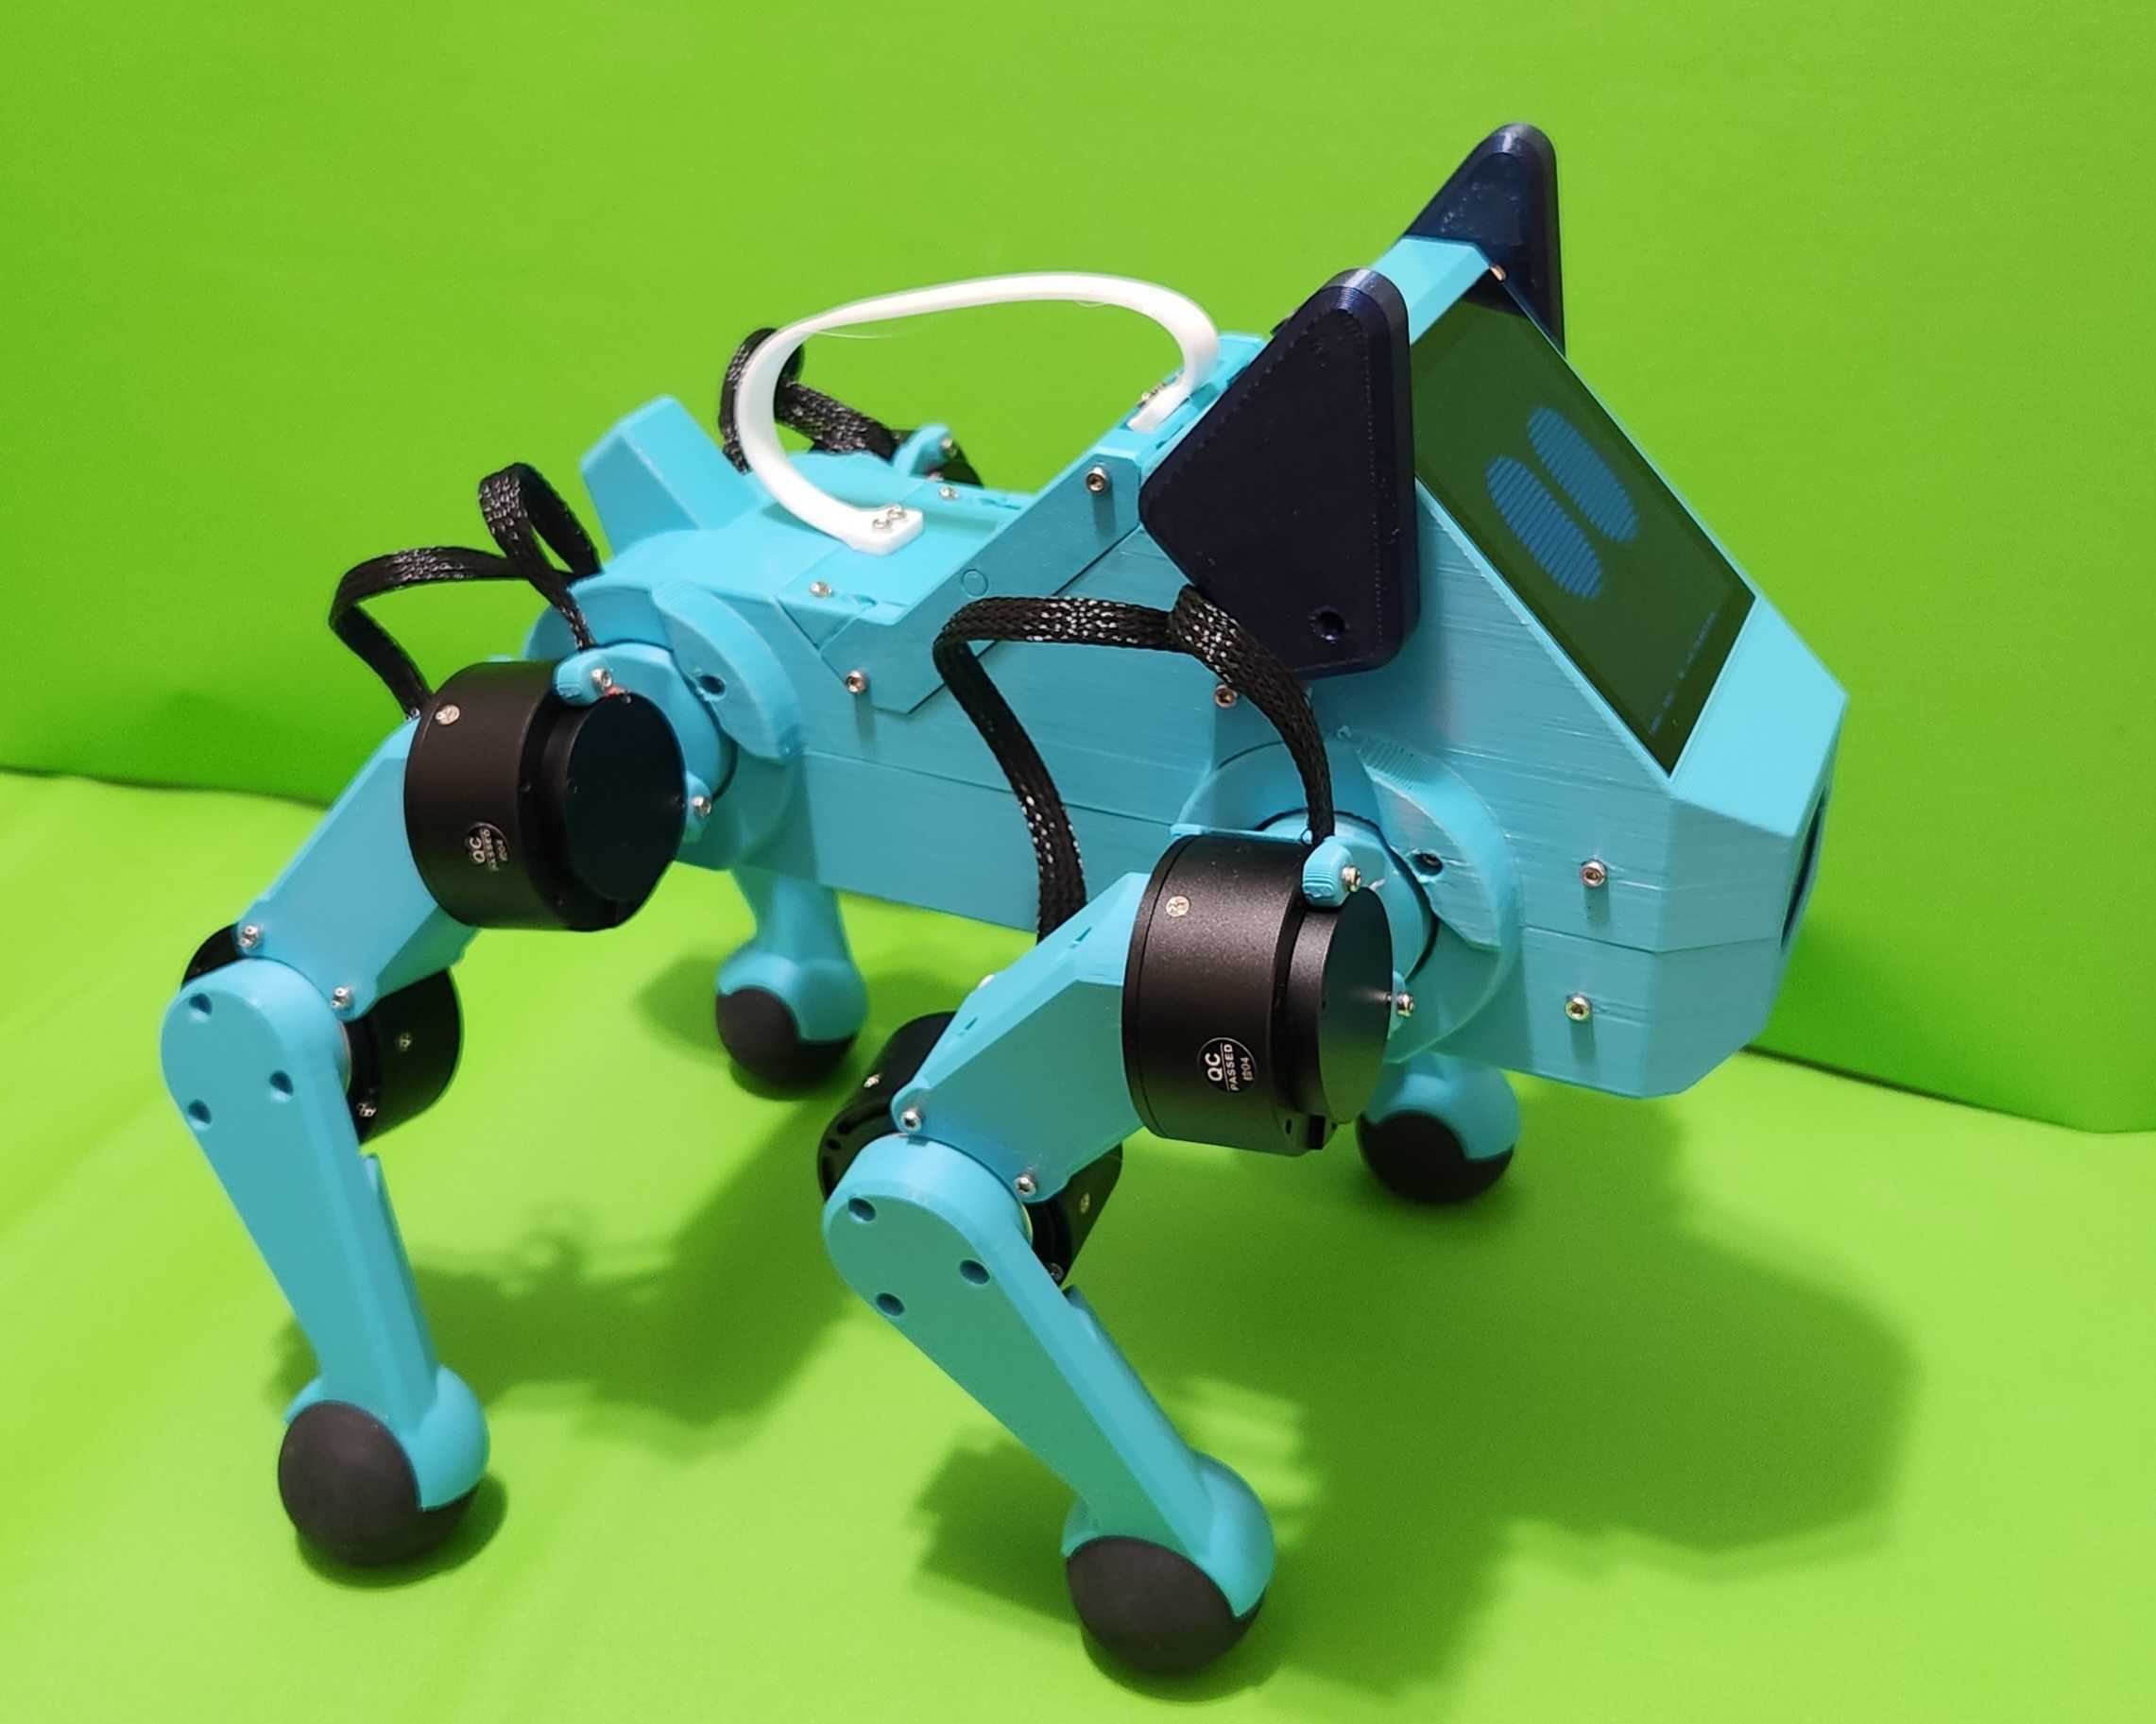
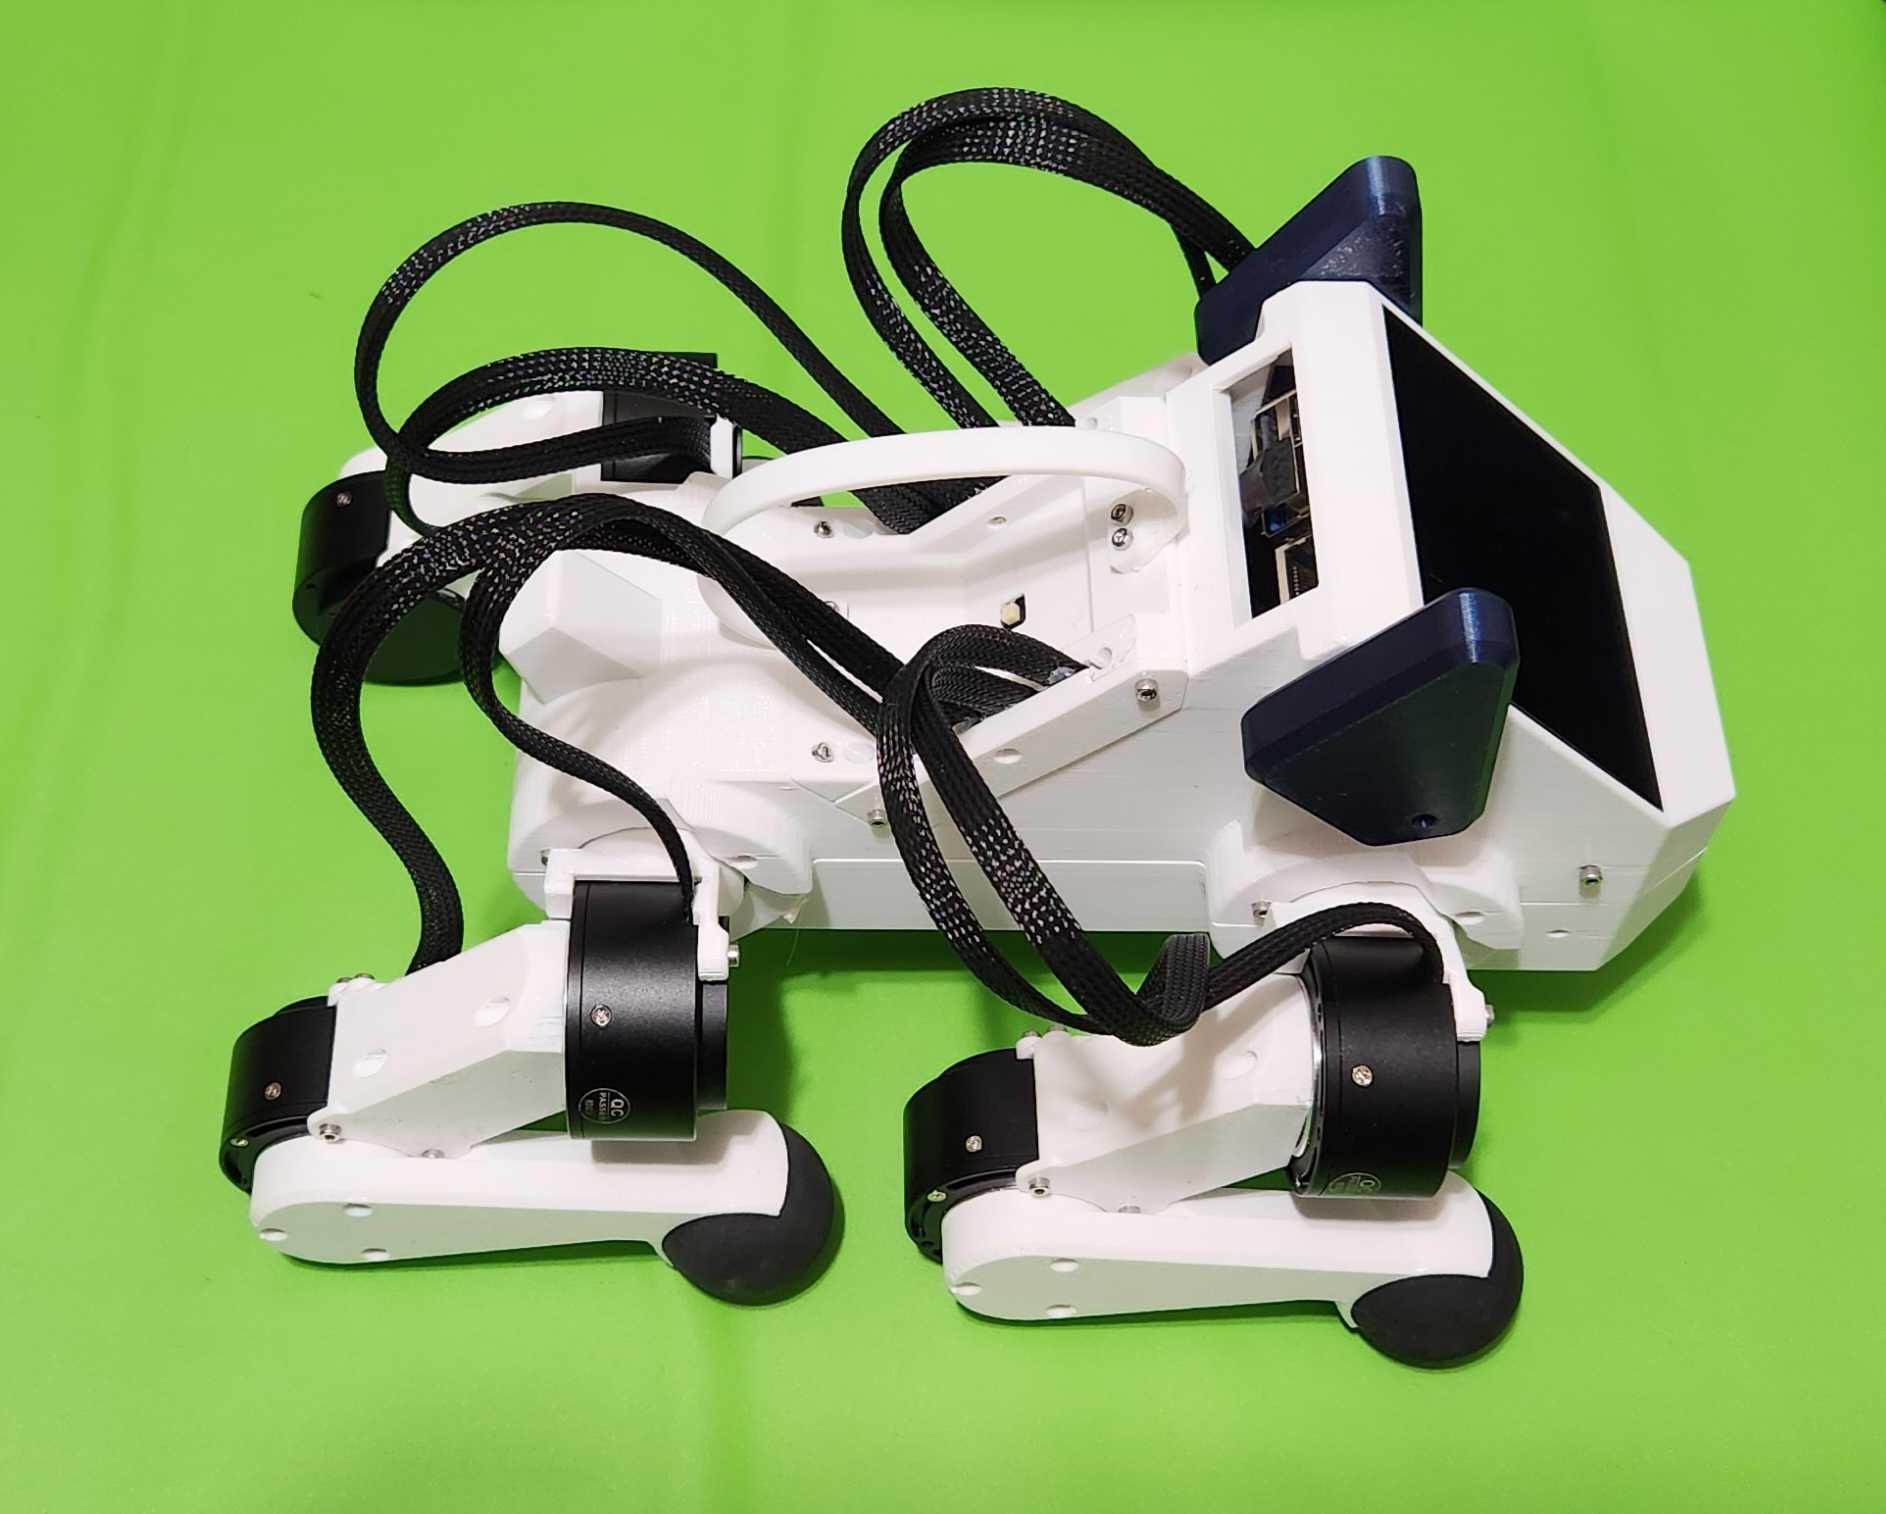
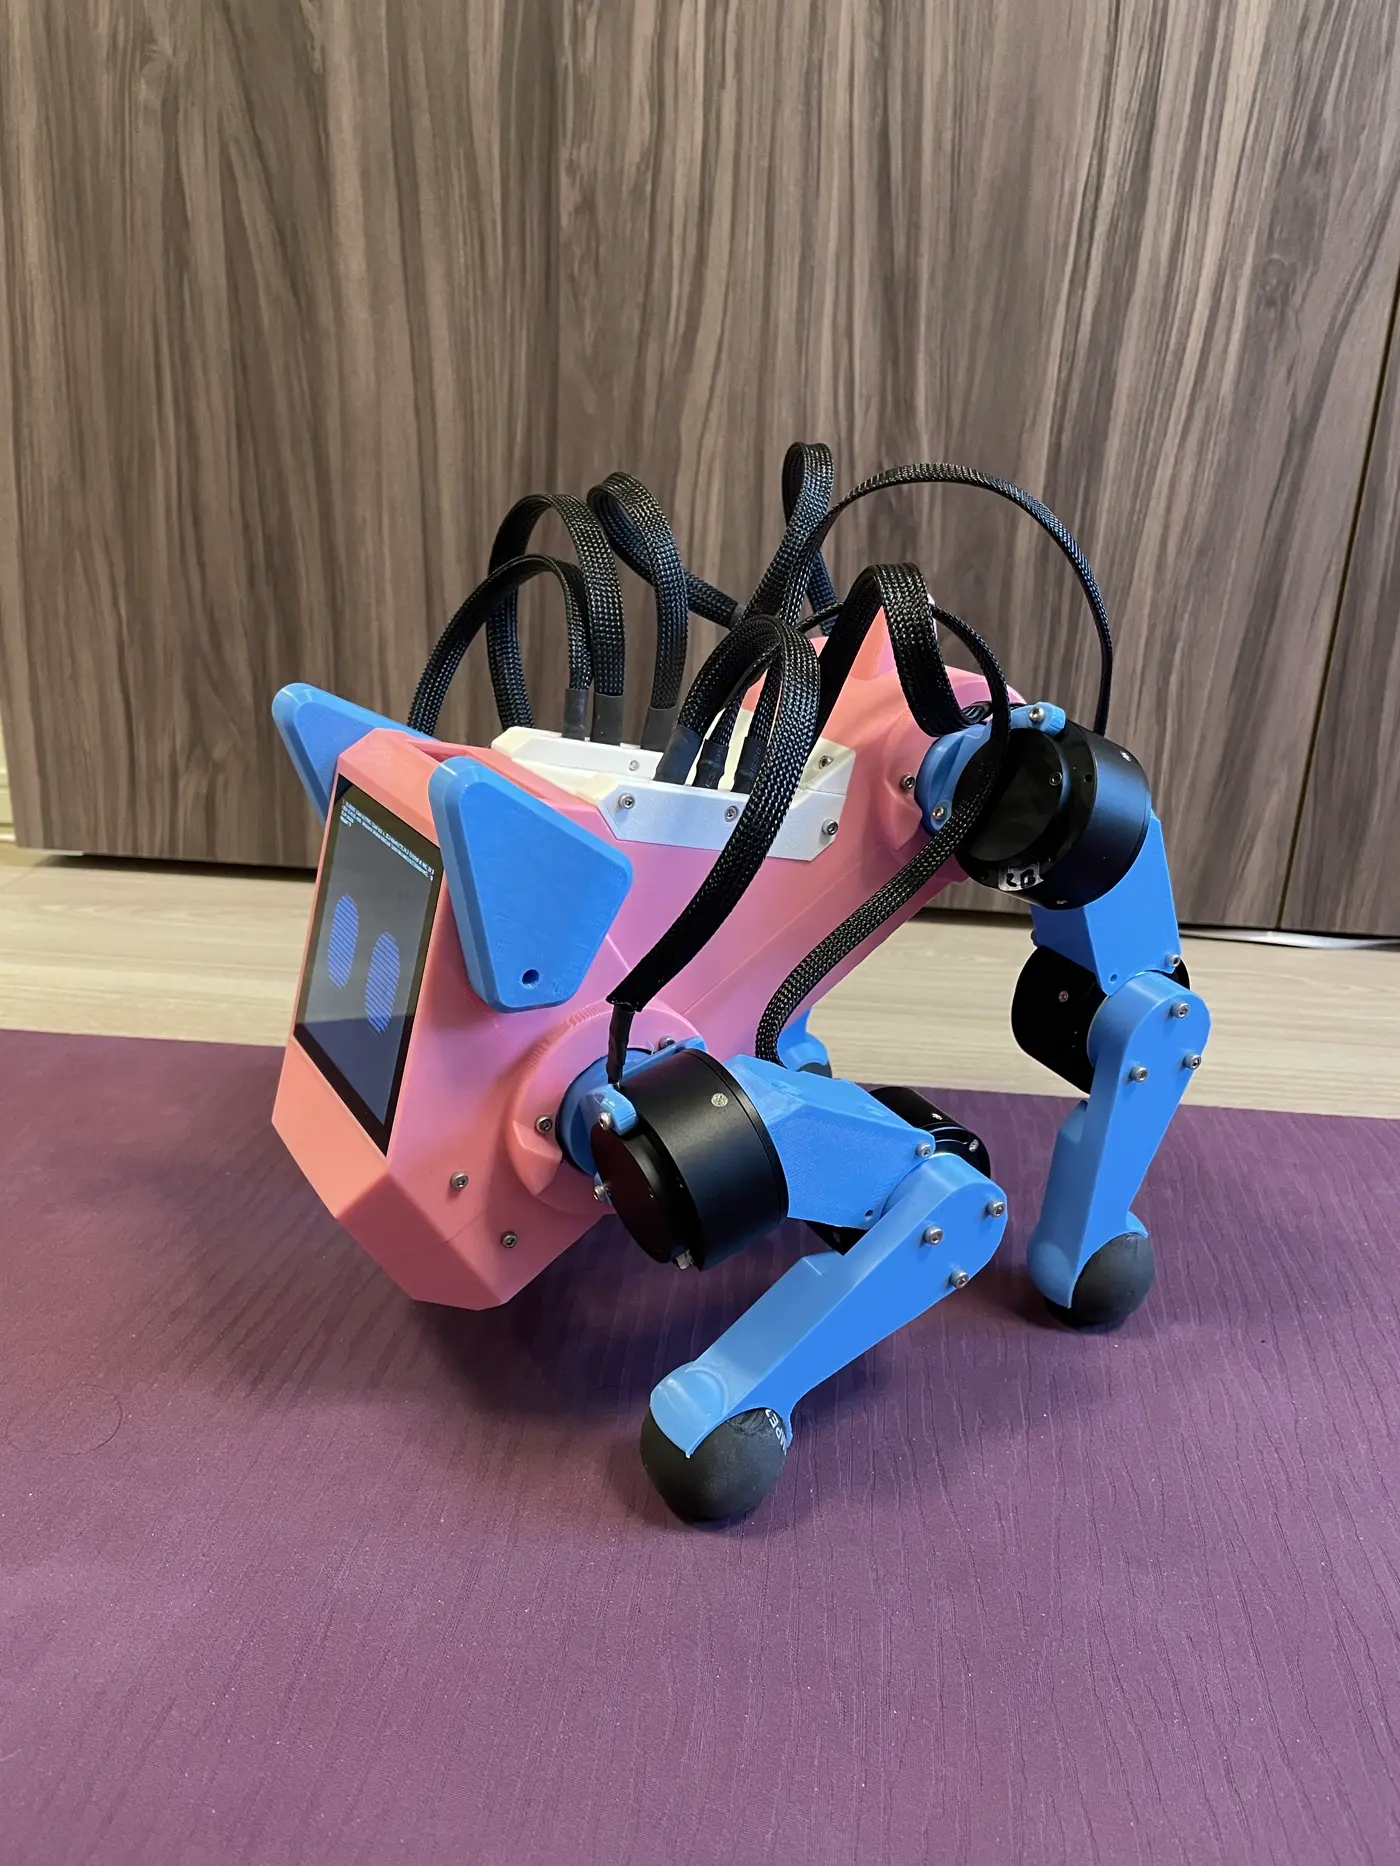
Build Stanford Pupper v3, a ~$1,000 RL-walking quadruped
Quad, Hard, $1,000
Stanford Robotics Club's Pupper v3 uses 400 W brushless motors, a Raspberry Pi 5, a depth camera and an RL locomotion policy out of the box, with a roughly $1,000 BOM.
Cost $1,000: Pupper v3 README BOM.
The original Pupper v1 repo is end-of-life and points to v3, which is fully open source. It's a serious but affordable research-grade dog.
Hardware & cost: GIM4305 brushless motors, Raspberry Pi 5, Luxonis depth camera. About $1,000 BOM per the README.
Difficulty: Hard.
Agent install prompt (paste into Claude Code, Cursor or Codex): "Read https://github.com/stanfordroboticsclub/StanfordQuadruped and find the Pupper v3 build docs it links to, then make me a parts checklist and the software setup steps for the Pi 5."
Source: stanfordroboticsclub/StanfordQuadruped on GitHub — https://github.com/stanfordroboticsclub/StanfordQuadruped (facts checked against the project README, Oct 2026; prices vary by region).
Quick answers
- How much does it cost to build Stanford Pupper v3?
- About $1,000, per the Pupper v3 README BOM.
- What do you need to build Stanford Pupper v3?
- GIM4305 brushless motors, Raspberry Pi 5, Luxonis depth camera. About $1,000 BOM per the README.
- How hard is it to build Stanford Pupper v3?
- Hard.
Ideas to try with it
Our ideas, not the builder's claims.
- Walk it around the office using the policy it ships with
- Use the depth camera to follow a person down a hallway
- Train a new gait in simulation and compare it on carpet and tile
1 more ideaShow fewer
- Bring it to a classroom to teach legged robotics
- Last commit
- 2024-10-24
- Builder
- stanfordroboticsclub
- Repo
- stanfordroboticsclub/StanfordQuadruped, 1,829 stars
- Built with
- Stanford Pupper
What to build next
Builds that share a board, robot or agent with this one.
 Program a robot cat or dog with Petoi OpenCatAnother robot dog
 Build a 3D-printed Spot Micro with ROS and SLAMAnother robot dog
 Write your own controller for a Unitree robot with SDK2Another robot dog
 Run ROS 2 Humble and Nav2 on a Mini PupperAnother robot dog
 Build Kame32, an 8-servo ESP32 robot dogAnother robot dog
 Build ToddlerBot, a low-cost open humanoid for learningAlso tagged #stanford